ControllerNode.hpp File Reference
Declaration of the ControllerNode class, a ROS 2 lifecycle node for speed computation in Easy Navigation. More...
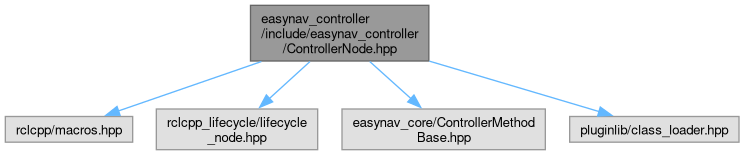
#include <memory>#include <mutex>#include <optional>#include <set>#include <string>#include "geometry_msgs/msg/twist.hpp"#include "geometry_msgs/msg/twist_stamped.hpp"#include "easynav_controller/VelocityMux.hpp"#include "easynav_controller/VelocitySmoother.hpp"#include "easynav_controller/safety/CommandGuard.hpp"#include "easynav_core/ControllerMethodBase.hpp"#include "easynav_core/RobotLimits.hpp"#include "easynav_core/SafetyChannel.hpp"#include "easynav_core/PluginSwitcher.hpp"#include "rclcpp/macros.hpp"#include "rclcpp_lifecycle/lifecycle_node.hpp"
Include dependency graph for ControllerNode.hpp:
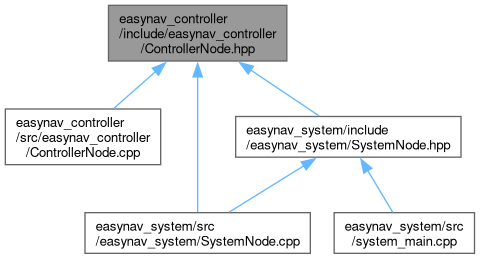
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Classes | |
| class | ControllerNode |
| ROS 2 lifecycle node that manages calculating speeds for the Easy Navigation system. More... | |
Namespaces | |
| namespace | easynav |
Detailed Description
Declaration of the ControllerNode class, a ROS 2 lifecycle node for speed computation in Easy Navigation.
Declaration of the ControllerNode class, a ROS 2 lifecycle node for calculating speeds tasks in Easy Navigation.
Generated by
 1.18.0