RealTime.cpp File Reference
Implementation of the real-time setup of the EasyNav process. More...
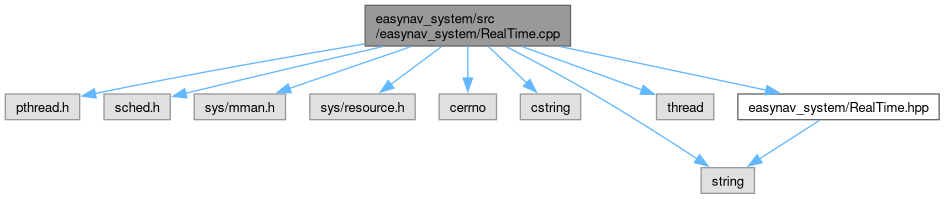
#include <pthread.h>#include <sched.h>#include <sys/mman.h>#include <sys/resource.h>#include <cerrno>#include <cstring>#include <string>#include <thread>#include "easynav_system/RealTime.hpp"
Include dependency graph for RealTime.cpp:
Namespaces | |
| namespace | easynav |
Functions | |
| std::string | check_memory_lock () |
| Whether lock_memory() is allowed (RLIMIT_MEMLOCK unlimited), without locking. | |
| std::string | check_real_time_priority (int priority) |
Whether a thread of this process can get SCHED_FIFO priority, tried on a temporary thread. | |
| std::string | lock_memory () |
| Locks the process memory, current and future, so the RT cycle never page-faults. | |
| std::string | set_real_time_priority (int priority) |
Gives the calling thread SCHED_FIFO priority. | |
Detailed Description
Implementation of the real-time setup of the EasyNav process.
Generated by
 1.18.0