VelocitySmoother.hpp File Reference
Declaration of the VelocitySmoother class. More...
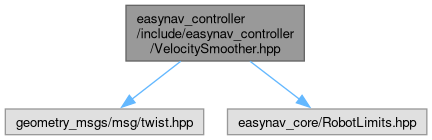
#include "geometry_msgs/msg/twist.hpp"#include "easynav_core/RobotLimits.hpp"
Include dependency graph for VelocitySmoother.hpp:
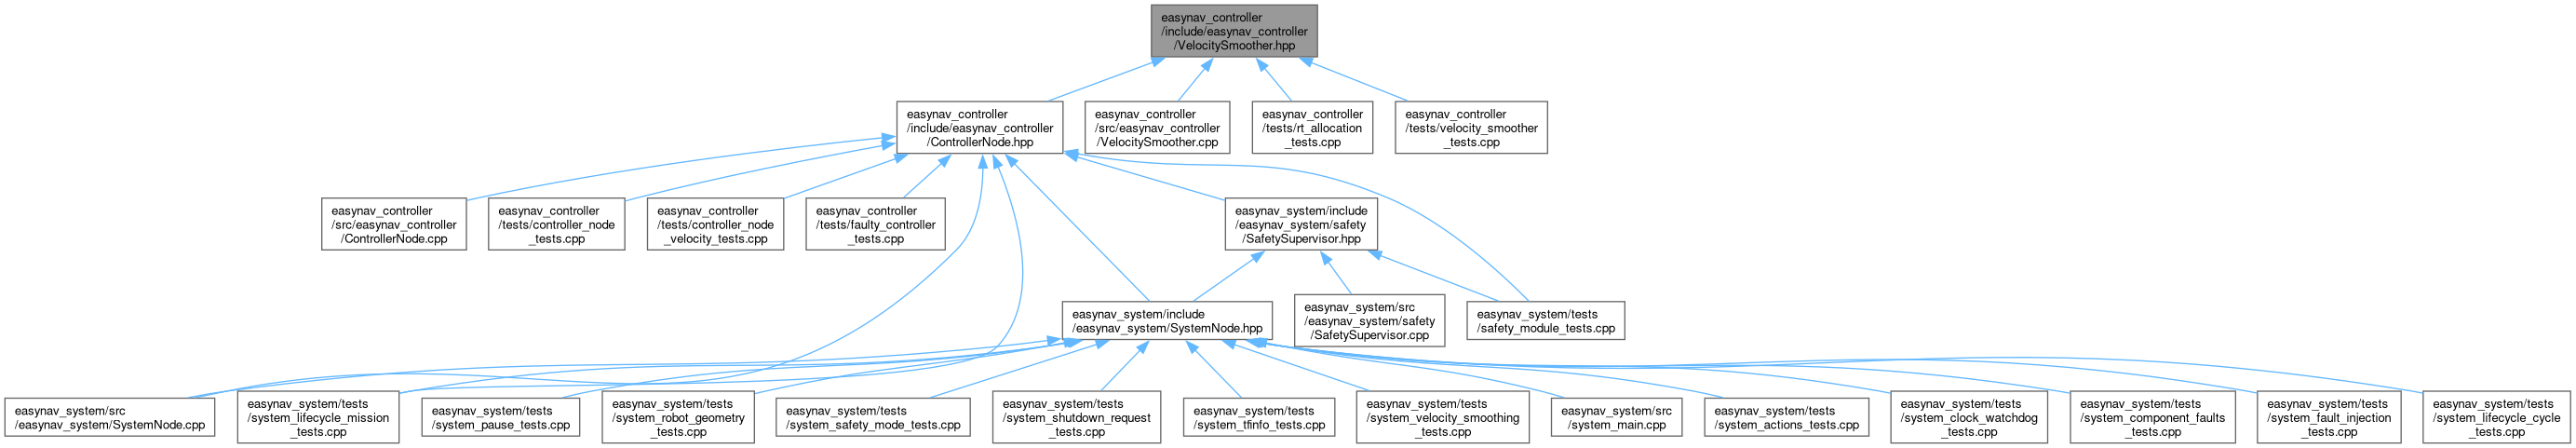
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Classes | |
| class | VelocitySmoother |
| Brings the commanded velocity towards a target within the robot limits. More... | |
Namespaces | |
| namespace | easynav |
Detailed Description
Declaration of the VelocitySmoother class.
Generated by
 1.18.0