ConfigurationFingerprint.cpp File Reference
Implementation of the configuration fingerprint. More...
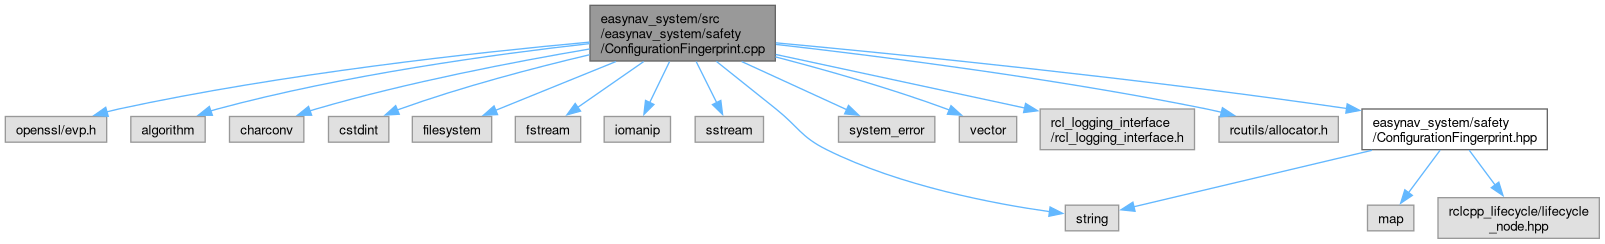
#include <openssl/evp.h>#include <algorithm>#include <charconv>#include <cstdint>#include <filesystem>#include <fstream>#include <iomanip>#include <sstream>#include <string>#include <system_error>#include <vector>#include "rcl_logging_interface/rcl_logging_interface.h"#include "rcutils/allocator.h"#include "easynav_system/safety/ConfigurationFingerprint.hpp"
Include dependency graph for ConfigurationFingerprint.cpp:
Namespaces | |
| namespace | easynav |
| namespace | easynav::safety |
Functions | |
| std::string | configuration_dump (const Nodes &nodes) |
Every parameter of nodes, one "node/parameter=value" per line, sorted. | |
| std::string | dump_file_name (const std::string &ns, const std::string &hash) |
"easynav_configuration_[<ns>_]<hash>.txt", for the EasyNav in namespace ns. | |
| std::string | loaded_plugins (const Nodes &nodes) |
| The loaded plugins: every "<alias>.plugin" listed in a "*_types" parameter, one "\n node: alias [class]" each. | |
| std::string | log_directory () |
| ROS's log directory ($ROS_LOG_DIR, else $ROS_HOME/log, else ~/.ros/log), or "". | |
| std::string | save_dump (const std::string &dump, const std::string &path) |
Writes dump to path, unless it already exists. | |
| std::string | sha256_hex (const std::string &data) |
SHA-256 of data, in hex. | |
Detailed Description
Implementation of the configuration fingerprint.
Generated by
 1.18.0