Protected Member Functions |
Static Protected Member Functions |
Protected Attributes |
Static Protected Attributes |
List of all members
GoalManagerInfoTest Class Reference
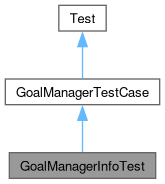
Inheritance diagram for GoalManagerInfoTest:
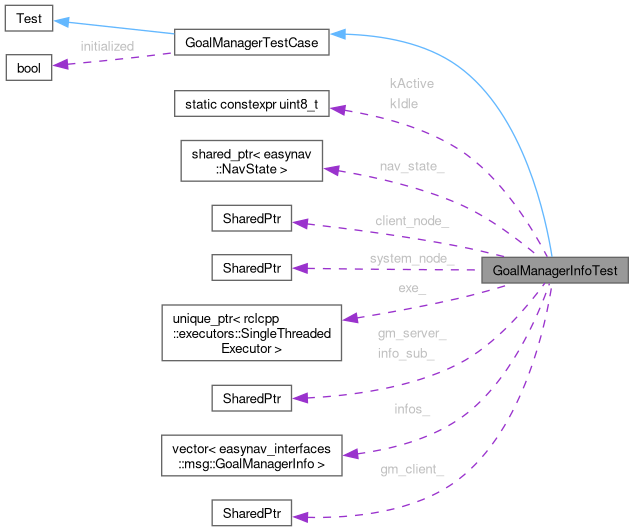
Collaboration diagram for GoalManagerInfoTest:
Protected Member Functions | |
| int | count (uint8_t status) const |
| void | set_robot (double x, double y) |
| void | SetUp () override |
| void | spin_for (std::chrono::milliseconds duration) |
| Protected Member Functions inherited from GoalManagerTestCase | |
| void | SetUp () |
| void | TearDown () |
| ~GoalManagerTestCase () | |
Static Protected Member Functions | |
| static geometry_msgs::msg::PoseStamped | goal_at (double x, double y) |
Protected Attributes | |
| rclcpp::Node::SharedPtr | client_node_ |
| std::unique_ptr< rclcpp::executors::SingleThreadedExecutor > | exe_ |
| easynav::GoalManagerClient::SharedPtr | gm_client_ |
| easynav::GoalManager::SharedPtr | gm_server_ |
| rclcpp::Subscription< easynav_interfaces::msg::GoalManagerInfo >::SharedPtr | info_sub_ |
| std::vector< easynav_interfaces::msg::GoalManagerInfo > | infos_ |
| std::shared_ptr< easynav::NavState > | nav_state_ |
| rclcpp_lifecycle::LifecycleNode::SharedPtr | system_node_ |
| Protected Attributes inherited from GoalManagerTestCase | |
| bool | initialized {false} |
Static Protected Attributes | |
| static constexpr uint8_t | kActive = easynav_interfaces::msg::GoalManagerInfo::ACTIVE |
| static constexpr uint8_t | kIdle = easynav_interfaces::msg::GoalManagerInfo::IDLE |
Member Function Documentation
◆ count()
|
protected |
◆ goal_at()
|
staticprotected |
◆ set_robot()
|
protected |
◆ SetUp()
|
overrideprotected |
◆ spin_for()
|
protected |
Member Data Documentation
◆ client_node_
|
protected |
◆ exe_
|
protected |
◆ gm_client_
|
protected |
◆ gm_server_
|
protected |
◆ info_sub_
|
protected |
◆ infos_
|
protected |
◆ kActive
|
staticconstexprprotected |
◆ kIdle
|
staticconstexprprotected |
◆ nav_state_
|
protected |
◆ system_node_
|
protected |
The documentation for this class was generated from the following file:
- easynav_system/tests/goalmanager_tests.cpp
Generated by
 1.18.0