SystemSafetyChannelTest Class Reference
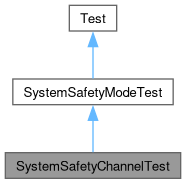
Inheritance diagram for SystemSafetyChannelTest:
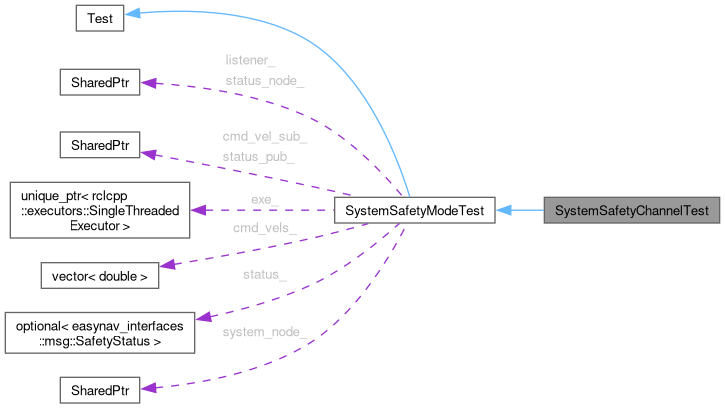
Collaboration diagram for SystemSafetyChannelTest:
Protected Member Functions | |
| std::vector< double > | run (std::chrono::milliseconds duration) |
| uint8_t | safety_level () |
| void | start_with_safety_status (std::vector< std::string > extra={}) |
| Protected Member Functions inherited from SystemSafetyModeTest | |
| bool | activate () |
| bool | configure () |
| void | connect_safety_channel () |
| void | expect_subnodes_in (uint8_t state) |
| void | listen_cmd_vel () |
| std::optional< diagnostic_msgs::msg::DiagnosticStatus > | rt_diagnostic () |
| void | run_rt_at_rate (std::chrono::milliseconds duration, bool real_time=false) |
| void | run_rt_cycles (int cycles, std::chrono::milliseconds gap) |
| std::optional< diagnostic_msgs::msg::DiagnosticStatus > | safety_diagnostic () |
| void | spin_for (std::chrono::milliseconds duration) |
| void | start (const std::vector< std::string > ¶ms) |
| rclcpp_lifecycle::LifecycleNode::SharedPtr | subnode (const std::string &name) |
| void | TearDown () override |
Static Protected Member Functions | |
| static void | expect_all_zero (const std::vector< double > &cmds) |
| Static Protected Member Functions inherited from SystemSafetyModeTest | |
| static easynav_interfaces::msg::SafetyStatus | channel_status (bool protective_stop, std::optional< double > speed_limit=std::nullopt) |
| static std::vector< std::string > | hanging_controller (double hang_time, double rt_freq=200.0, std::vector< std::string > extra={}, int fault_after=20) |
Additional Inherited Members | |
| Protected Attributes inherited from SystemSafetyModeTest | |
| rclcpp::Subscription< geometry_msgs::msg::Twist >::SharedPtr | cmd_vel_sub_ |
| std::vector< double > | cmd_vels_ |
| std::unique_ptr< rclcpp::executors::SingleThreadedExecutor > | exe_ |
| rclcpp::Node::SharedPtr | listener_ |
| std::optional< easynav_interfaces::msg::SafetyStatus > | status_ |
| rclcpp::Node::SharedPtr | status_node_ |
| rclcpp::Publisher< easynav_interfaces::msg::SafetyStatus >::SharedPtr | status_pub_ |
| easynav::SystemNode::SharedPtr | system_node_ |
Member Function Documentation
◆ expect_all_zero()
|
staticprotected |
◆ run()
|
protected |
◆ safety_level()
|
protected |
◆ start_with_safety_status()
|
protected |
The documentation for this class was generated from the following file:
- easynav_system/tests/system_safety_mode_tests.cpp
Generated by
 1.18.0