Costs.hpp File Reference
Values of a U8 cost layer, as in costmap_2d / Nav2 (so that bridging to them is a copy). More...
#include <cstdint>
Include dependency graph for Costs.hpp:
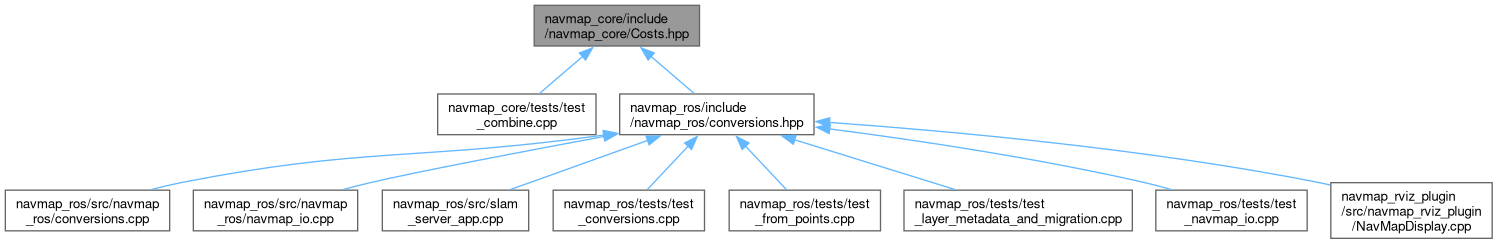
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Namespaces | |
| namespace | navmap |
Variables | |
| constexpr std::uint8_t | FREE_SPACE = 0 |
| Known free. | |
| constexpr std::uint8_t | INSCRIBED_INFLATED_OBSTACLE = 253 |
| The robot would touch an obstacle. | |
| constexpr std::uint8_t | LETHAL_OBSTACLE = 254 |
| Obstacle. | |
| constexpr std::uint8_t | MAX_NON_OBSTACLE = 252 |
| Highest traversable cost. | |
| constexpr std::uint8_t | NO_INFORMATION = 255 |
| Unknown, not observed. | |
Detailed Description
Values of a U8 cost layer, as in costmap_2d / Nav2 (so that bridging to them is a copy).
Generated by
 1.18.0