DescriptorParams Struct Reference
Which descriptors to compute, and over which neighbourhoods. More...
#include <Descriptors.hpp>
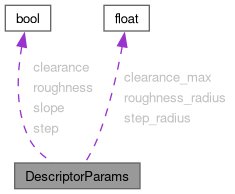
Collaboration diagram for DescriptorParams:
Public Attributes | |
| bool | clearance {true} |
| "clearance": free height to the next surface above (m) | |
| float | clearance_max {10.0f} |
| Beyond this, no surface above: +inf. | |
| bool | roughness {true} |
| "roughness": RMS distance to the plane fitted in a disc (m) | |
| float | roughness_radius {0.3f} |
| Disc for the roughness plane fit (m). | |
| bool | slope {true} |
| "slope": angle of the NavCel normal to the vertical (deg) | |
| bool | step {true} |
| "step": height span of the vertices in a disc (m) | |
| float | step_radius {0.2f} |
| Disc for the step (m). | |
Detailed Description
Which descriptors to compute, and over which neighbourhoods.
Member Data Documentation
◆ clearance
| bool clearance {true} |
"clearance": free height to the next surface above (m)
◆ clearance_max
| float clearance_max {10.0f} |
Beyond this, no surface above: +inf.
◆ roughness
| bool roughness {true} |
"roughness": RMS distance to the plane fitted in a disc (m)
◆ roughness_radius
| float roughness_radius {0.3f} |
Disc for the roughness plane fit (m).
◆ slope
| bool slope {true} |
"slope": angle of the NavCel normal to the vertical (deg)
◆ step
| bool step {true} |
"step": height span of the vertices in a disc (m)
◆ step_radius
| float step_radius {0.2f} |
Disc for the step (m).
The documentation for this struct was generated from the following file:
- navmap_core/include/navmap_core/Descriptors.hpp
Generated by
 1.18.0