SimplifyParams Struct Reference
Parameters of simplify(). More...
#include <Simplify.hpp>
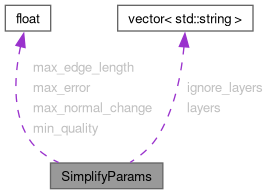
Collaboration diagram for SimplifyParams:
Public Attributes | |
| std::vector< std::string > | ignore_layers |
| Layers left out of the above (e.g. | |
| std::vector< std::string > | layers |
| Layers whose values must not change anywhere; empty: all the layers of the map. | |
| float | max_edge_length {std::numeric_limits<float>::infinity()} |
| No edge longer than this (m). Bounds the NavCel size, e.g. to keep marking obstacles fine. | |
| float | max_error {0.02f} |
| Geometric error (m): every vertex stays within this distance of the planes of the original NavCels it replaces (quadric error), and of the open edges it moves along. | |
| float | max_normal_change {30.0f} |
| Maximum rotation (deg) of a NavCel's normal with respect to the original one. | |
| float | min_quality {0.15f} |
| Minimum NavCel quality, 4·sqrt(3)·area / sum of squared edges (1 equilateral, 0 flat). | |
Detailed Description
Parameters of simplify().
Member Data Documentation
◆ ignore_layers
| std::vector<std::string> ignore_layers |
Layers left out of the above (e.g.
per-cell geometry such as "elevation"). They are carried from the NavCel that survives, so recompute them if they depend on its shape.
◆ layers
| std::vector<std::string> layers |
Layers whose values must not change anywhere; empty: all the layers of the map.
◆ max_edge_length
| float max_edge_length {std::numeric_limits<float>::infinity()} |
No edge longer than this (m). Bounds the NavCel size, e.g. to keep marking obstacles fine.
◆ max_error
| float max_error {0.02f} |
Geometric error (m): every vertex stays within this distance of the planes of the original NavCels it replaces (quadric error), and of the open edges it moves along.
◆ max_normal_change
| float max_normal_change {30.0f} |
Maximum rotation (deg) of a NavCel's normal with respect to the original one.
◆ min_quality
| float min_quality {0.15f} |
Minimum NavCel quality, 4·sqrt(3)·area / sum of squared edges (1 equilateral, 0 flat).
The documentation for this struct was generated from the following file:
- navmap_core/include/navmap_core/Simplify.hpp
Generated by
 1.18.0