#include <gtest/gtest.h>#include <algorithm>#include <cmath>#include <cstdint>#include <functional>#include <limits>#include <map>#include <random>#include <set>#include <utility>#include <vector>#include "navmap_core/NavMap.hpp"#include "navmap_ros/conversions.hpp"#include "pcl_conversions/pcl_conversions.h"
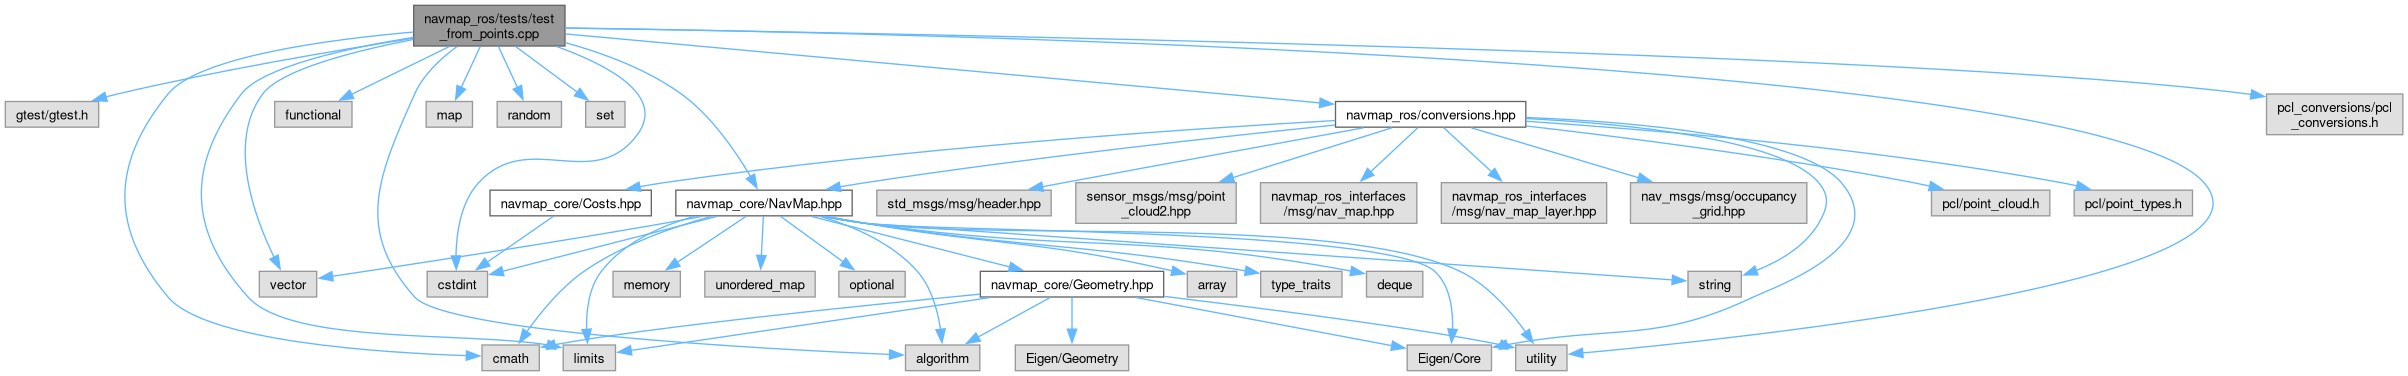
Include dependency graph for test_from_points.cpp:
Typedefs | |
| using | Cloud = pcl::PointCloud<pcl::PointXYZ> |
| using | NavCelId |
| Index of a triangle (NavCel) within the global mesh. | |
Functions | |
| TEST (FromPoints, BoxOnTheFloorIsAHole) | |
| TEST (FromPoints, DegenerateInputsGiveEmptyMaps) | |
| TEST (FromPoints, ElevationLayerIsMeanVertexHeight) | |
| TEST (FromPoints, FlatPlaneIsAFullManifoldGrid) | |
| TEST (FromPoints, HighStepSplitsLowStepJoins) | |
| TEST (FromPoints, HoleFillingLimits) | |
| TEST (FromPoints, HoleSharedByTwoFloorsIsFilledOnBoth) | |
| TEST (FromPoints, IrregularDensityStaysOneCleanSheet) | |
| TEST (FromPoints, IsolatedOutliersAddNothing) | |
| TEST (FromPoints, LatticeAlignedSamplesFillEveryCell) | |
| TEST (FromPoints, MaxSurfacesDropsTrianglesAndVertices) | |
| TEST (FromPoints, MinClearanceDecidesWhatIsALevel) | |
| TEST (FromPoints, MinSurfaceAreaDropsSmallSurfaces) | |
| TEST (FromPoints, NoisyPlaneStaysOneSheet) | |
| TEST (FromPoints, NonFinitePointsAreIgnored) | |
| TEST (FromPoints, PitWithObservedBottomIsNotFilled) | |
| TEST (FromPoints, PointCloud2EntryMatchesPcl) | |
| TEST (FromPoints, PointOrderDoesNotMatter) | |
| TEST (FromPoints, PotholeIsNotLiftedToTheFloor) | |
| TEST (FromPoints, RampConnectsGroundAndUpperFloor) | |
| TEST (FromPoints, SlabSupportIsItsUpperFace) | |
| TEST (FromPoints, SlopeHeightIsTakenAtTheCellCentre) | |
| TEST (FromPoints, SlopeLimit) | |
| TEST (FromPoints, SmallEnclosedHoleIsFilledAndMarked) | |
| TEST (FromPoints, SparseUpperFaceOfASlabIsRecoveredByItsNeighbours) | |
| TEST (FromPoints, SpikesDoNotRaiseTheSurface) | |
| TEST (FromPoints, SupportCountsPointsOfTheWeakestVertex) | |
| TEST (FromPoints, TwoStackedFloorsAreTwoSurfaces) | |
| TEST (FromPoints, VoxelizedCloudGivesOneSheet) | |
| TEST (FromPoints, WallSplitsTheFloor) | |
| TEST (FromPointsViewpoints, CeilingSeenFromBelowIsDropped) | |
| TEST (FromPointsViewpoints, CrestSeenFromTheFootOfItsSlopeIsKept) | |
| TEST (FromPointsViewpoints, DescendingRaysNeverSeeFromBelow) | |
| TEST (FromPointsViewpoints, DisabledFiltersMatchThePlainCloud) | |
| TEST (FromPointsViewpoints, EmptyAndDegenerateInputs) | |
| TEST (FromPointsViewpoints, FarCeilingSeenByGrazingRaysIsDropped) | |
| TEST (FromPointsViewpoints, FilterIsDeterministic) | |
| TEST (FromPointsViewpoints, GrazingRaysDoNotEatTheFloor) | |
| TEST (FromPointsViewpoints, PersonSeenThroughIsCarved) | |
| TEST (FromPointsViewpoints, PointsWithoutViewpointAreKept) | |
| TEST (FromPointsViewpoints, RampSeenFromItsFootIsKept) | |
| TEST (FromPointsViewpoints, TableUndersideStillBlocksTheFloor) | |
| TEST (FromPointsViewpoints, UpperFloorStandsOnItsTopFace) | |
| TEST (FromPointsViewpoints, WallSeenByUpwardRingsIsKept) | |
Typedef Documentation
◆ Cloud
| using Cloud = pcl::PointCloud<pcl::PointXYZ> |
◆ NavCelId
| using NavCelId |
Index of a triangle (NavCel) within the global mesh.
Function Documentation
◆ TEST() [1/44]
| TEST | ( | FromPoints | , |
| BoxOnTheFloorIsAHole | ) |
◆ TEST() [2/44]
| TEST | ( | FromPoints | , |
| DegenerateInputsGiveEmptyMaps | ) |
◆ TEST() [3/44]
| TEST | ( | FromPoints | , |
| ElevationLayerIsMeanVertexHeight | ) |
◆ TEST() [4/44]
| TEST | ( | FromPoints | , |
| FlatPlaneIsAFullManifoldGrid | ) |
◆ TEST() [5/44]
| TEST | ( | FromPoints | , |
| HighStepSplitsLowStepJoins | ) |
◆ TEST() [6/44]
| TEST | ( | FromPoints | , |
| HoleFillingLimits | ) |
◆ TEST() [7/44]
| TEST | ( | FromPoints | , |
| HoleSharedByTwoFloorsIsFilledOnBoth | ) |
◆ TEST() [8/44]
| TEST | ( | FromPoints | , |
| IrregularDensityStaysOneCleanSheet | ) |
◆ TEST() [9/44]
| TEST | ( | FromPoints | , |
| IsolatedOutliersAddNothing | ) |
◆ TEST() [10/44]
| TEST | ( | FromPoints | , |
| LatticeAlignedSamplesFillEveryCell | ) |
◆ TEST() [11/44]
| TEST | ( | FromPoints | , |
| MaxSurfacesDropsTrianglesAndVertices | ) |
◆ TEST() [12/44]
| TEST | ( | FromPoints | , |
| MinClearanceDecidesWhatIsALevel | ) |
◆ TEST() [13/44]
| TEST | ( | FromPoints | , |
| MinSurfaceAreaDropsSmallSurfaces | ) |
◆ TEST() [14/44]
| TEST | ( | FromPoints | , |
| NoisyPlaneStaysOneSheet | ) |
◆ TEST() [15/44]
| TEST | ( | FromPoints | , |
| NonFinitePointsAreIgnored | ) |
◆ TEST() [16/44]
| TEST | ( | FromPoints | , |
| PitWithObservedBottomIsNotFilled | ) |
◆ TEST() [17/44]
| TEST | ( | FromPoints | , |
| PointCloud2EntryMatchesPcl | ) |
◆ TEST() [18/44]
| TEST | ( | FromPoints | , |
| PointOrderDoesNotMatter | ) |
◆ TEST() [19/44]
| TEST | ( | FromPoints | , |
| PotholeIsNotLiftedToTheFloor | ) |
◆ TEST() [20/44]
| TEST | ( | FromPoints | , |
| RampConnectsGroundAndUpperFloor | ) |
◆ TEST() [21/44]
| TEST | ( | FromPoints | , |
| SlabSupportIsItsUpperFace | ) |
◆ TEST() [22/44]
| TEST | ( | FromPoints | , |
| SlopeHeightIsTakenAtTheCellCentre | ) |
◆ TEST() [23/44]
| TEST | ( | FromPoints | , |
| SlopeLimit | ) |
◆ TEST() [24/44]
| TEST | ( | FromPoints | , |
| SmallEnclosedHoleIsFilledAndMarked | ) |
◆ TEST() [25/44]
| TEST | ( | FromPoints | , |
| SparseUpperFaceOfASlabIsRecoveredByItsNeighbours | ) |
◆ TEST() [26/44]
| TEST | ( | FromPoints | , |
| SpikesDoNotRaiseTheSurface | ) |
◆ TEST() [27/44]
| TEST | ( | FromPoints | , |
| SupportCountsPointsOfTheWeakestVertex | ) |
◆ TEST() [28/44]
| TEST | ( | FromPoints | , |
| TwoStackedFloorsAreTwoSurfaces | ) |
◆ TEST() [29/44]
| TEST | ( | FromPoints | , |
| VoxelizedCloudGivesOneSheet | ) |
◆ TEST() [30/44]
| TEST | ( | FromPoints | , |
| WallSplitsTheFloor | ) |
◆ TEST() [31/44]
| TEST | ( | FromPointsViewpoints | , |
| CeilingSeenFromBelowIsDropped | ) |
◆ TEST() [32/44]
| TEST | ( | FromPointsViewpoints | , |
| CrestSeenFromTheFootOfItsSlopeIsKept | ) |
◆ TEST() [33/44]
| TEST | ( | FromPointsViewpoints | , |
| DescendingRaysNeverSeeFromBelow | ) |
◆ TEST() [34/44]
| TEST | ( | FromPointsViewpoints | , |
| DisabledFiltersMatchThePlainCloud | ) |
◆ TEST() [35/44]
| TEST | ( | FromPointsViewpoints | , |
| EmptyAndDegenerateInputs | ) |
◆ TEST() [36/44]
| TEST | ( | FromPointsViewpoints | , |
| FarCeilingSeenByGrazingRaysIsDropped | ) |
◆ TEST() [37/44]
| TEST | ( | FromPointsViewpoints | , |
| FilterIsDeterministic | ) |
◆ TEST() [38/44]
| TEST | ( | FromPointsViewpoints | , |
| GrazingRaysDoNotEatTheFloor | ) |
◆ TEST() [39/44]
| TEST | ( | FromPointsViewpoints | , |
| PersonSeenThroughIsCarved | ) |
◆ TEST() [40/44]
| TEST | ( | FromPointsViewpoints | , |
| PointsWithoutViewpointAreKept | ) |
◆ TEST() [41/44]
| TEST | ( | FromPointsViewpoints | , |
| RampSeenFromItsFootIsKept | ) |
◆ TEST() [42/44]
| TEST | ( | FromPointsViewpoints | , |
| TableUndersideStillBlocksTheFloor | ) |
◆ TEST() [43/44]
| TEST | ( | FromPointsViewpoints | , |
| UpperFloorStandsOnItsTopFace | ) |
◆ TEST() [44/44]
| TEST | ( | FromPointsViewpoints | , |
| WallSeenByUpwardRingsIsKept | ) |
Generated by
 1.18.0