test_layers_unknown_occupancy.cpp File Reference
#include <gtest/gtest.h>#include <algorithm>#include <cmath>#include <cstdint>#include <limits>#include <random>#include <vector>#include "navmap_core/NavMap.hpp"#include "navmap_core/Occupancy.hpp"
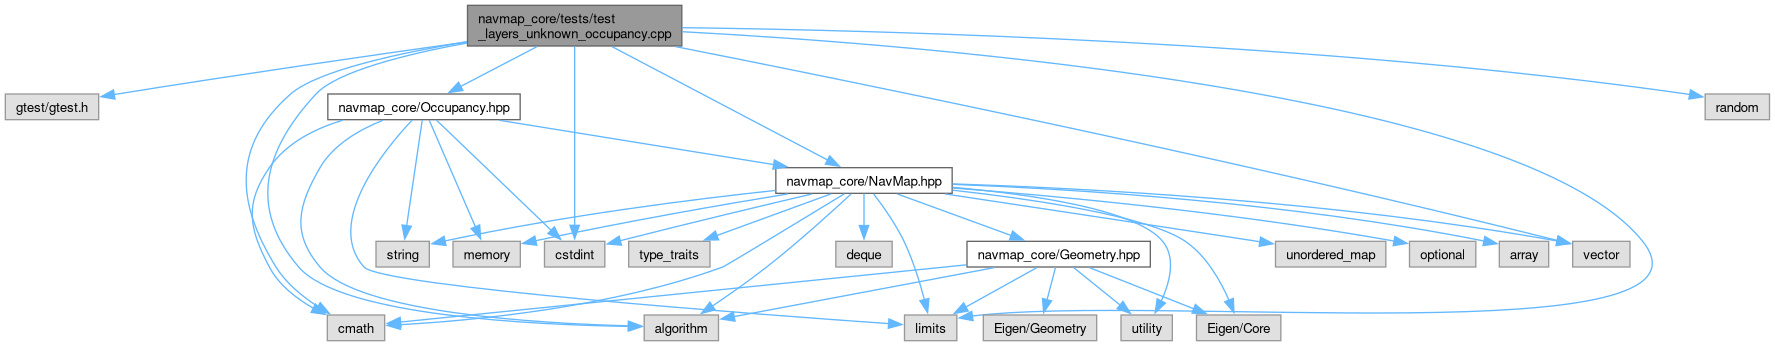
Include dependency graph for test_layers_unknown_occupancy.cpp:
Classes | |
| class | OccupancyLayer |
| Log-odds occupancy over an int16 layer of a NavMap. More... | |
| struct | OccupancyParams |
| Probabilities of the update rule and of the classification (OctoMap defaults). More... | |
Typedefs | |
| using | NavCelId |
| Index of a triangle (NavCel) within the global mesh. | |
Enumerations | |
| enum class | OccupancyState |
| Three-state classification of a NavCel. More... | |
Functions | |
| TEST (LayersI16, CopiesAssignmentsAndHashes) | |
| TEST (LayersI16, StoresSignedValuesAndConvertsBothWays) | |
| TEST (LayerUnknown, DeclaredPerLayerForIntegersAndNaN) | |
| TEST (Occupancy, CustomParametersAndDirtyHash) | |
| TEST (Occupancy, FixedPointValuesOfTheOctoMapDefaults) | |
| TEST (Occupancy, MatchesTheFloatRuleWithinRounding) | |
| TEST (Occupancy, NewCellsAreUnknownAndTheLayerTravelsWithTheMap) | |
| TEST (Occupancy, SequencesClampAndClassify) | |
Typedef Documentation
◆ NavCelId
| using NavCelId |
Index of a triangle (NavCel) within the global mesh.
Enumeration Type Documentation
◆ OccupancyState
|
strong |
Three-state classification of a NavCel.
Function Documentation
◆ TEST() [1/8]
| TEST | ( | LayersI16 | , |
| CopiesAssignmentsAndHashes | ) |
◆ TEST() [2/8]
| TEST | ( | LayersI16 | , |
| StoresSignedValuesAndConvertsBothWays | ) |
◆ TEST() [3/8]
| TEST | ( | LayerUnknown | , |
| DeclaredPerLayerForIntegersAndNaN | ) |
◆ TEST() [4/8]
| TEST | ( | Occupancy | , |
| CustomParametersAndDirtyHash | ) |
◆ TEST() [5/8]
| TEST | ( | Occupancy | , |
| FixedPointValuesOfTheOctoMapDefaults | ) |
◆ TEST() [6/8]
| TEST | ( | Occupancy | , |
| MatchesTheFloatRuleWithinRounding | ) |
◆ TEST() [7/8]
| TEST | ( | Occupancy | , |
| NewCellsAreUnknownAndTheLayerTravelsWithTheMap | ) |
◆ TEST() [8/8]
| TEST | ( | Occupancy | , |
| SequencesClampAndClassify | ) |
Generated by
 1.18.0