SystemReconfigureTest Class Reference
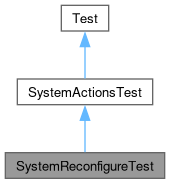
Inheritance diagram for SystemReconfigureTest:
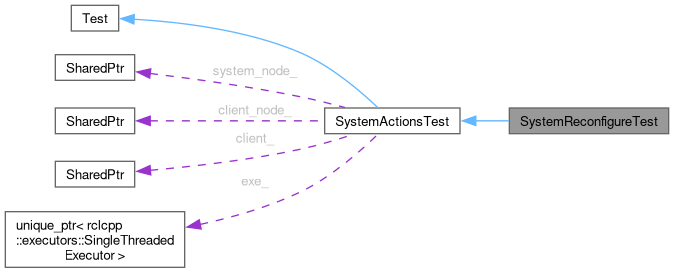
Collaboration diagram for SystemReconfigureTest:
Protected Member Functions | |
| bool | active () |
| easynav::RobotLimits | limits () |
| void | make_active () |
| double | max_linear_vel () |
| rclcpp_lifecycle::LifecycleNode::SharedPtr | node (const std::string &name) |
| std::vector< std::string > | reconfigured () |
| Protected Member Functions inherited from SystemActionsTest | |
| void | cycle_for (std::chrono::milliseconds duration) |
| bool | cycle_until (const std::function< bool()> &done, std::chrono::milliseconds timeout=3s) |
| bool | finished () |
| void | SetUp () override |
| void | start_mission () |
| bool | transition_to (uint8_t transition, uint8_t expected) |
Static Protected Member Functions | |
| static std::vector< easynav::ParameterChange > | max_linear_vel_to (double value) |
| Static Protected Member Functions inherited from SystemActionsTest | |
| static void | set_robot_x (easynav::NavState &nav_state, double x) |
Additional Inherited Members | |
| Protected Attributes inherited from SystemActionsTest | |
| easynav::GoalManagerClient::SharedPtr | client_ |
| rclcpp::Node::SharedPtr | client_node_ |
| std::unique_ptr< rclcpp::executors::SingleThreadedExecutor > | exe_ |
| easynav::SystemNode::SharedPtr | system_node_ |
Member Function Documentation
◆ active()
|
protected |
◆ limits()
|
protected |
◆ make_active()
|
protected |
◆ max_linear_vel()
|
protected |
◆ max_linear_vel_to()
|
staticprotected |
◆ node()
|
protected |
◆ reconfigured()
|
protected |
The documentation for this class was generated from the following file:
- easynav_system/tests/system_actions_tests.cpp
Generated by
 1.18.0