YTSession Class Reference
A Yaets Tracing Session. More...
#include <YTSession.hpp>
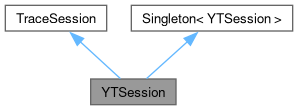
Inheritance diagram for YTSession:
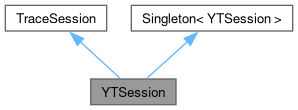
Collaboration diagram for YTSession:
Public Member Functions | |
| YTSession (const std::string &ros_namespace="") | |
| ~YTSession () | |
Additional Inherited Members | |
| Static Public Member Functions inherited from Singleton< YTSession > | |
| static YTSession & | get (Args &&... args) |
| static YTSession * | getInstance (Args &&... args) |
| static void | removeInstance () |
| Destroy the current instance, if any; the next getInstance()/get() call creates a fresh one. | |
| Protected Member Functions inherited from Singleton< YTSession > | |
| Singleton & | operator= (const Singleton &)=delete |
| Singleton ()=default | |
| ~Singleton ()=default | |
Detailed Description
A Yaets Tracing Session.
Constructor & Destructor Documentation
◆ YTSession()
|
explicit |
- Parameters
-
ros_namespace The owning node's ROS namespace (e.g. "/robot_1" or "/"), used to pick this instance's trace log path – see log_path(). Only the first call across getInstance()/get() overloads (from any translation unit) actually constructs the singleton, so this must be supplied before any EASYNAV_TRACE_EVENT/EASYNAV_TRACE_NAMED_EVENT fires; system_main.cpp does this right after creating system_node.
◆ ~YTSession()
| ~YTSession | ( | ) |
The documentation for this class was generated from the following file:
- easynav_common/include/easynav_common/YTSession.hpp
Generated by
 1.18.0