ControllerNode as the single exit of the velocity command: robot limits for the controller plugins, selection among sources (mux), smoothing, publication, and braking on deactivation. More...
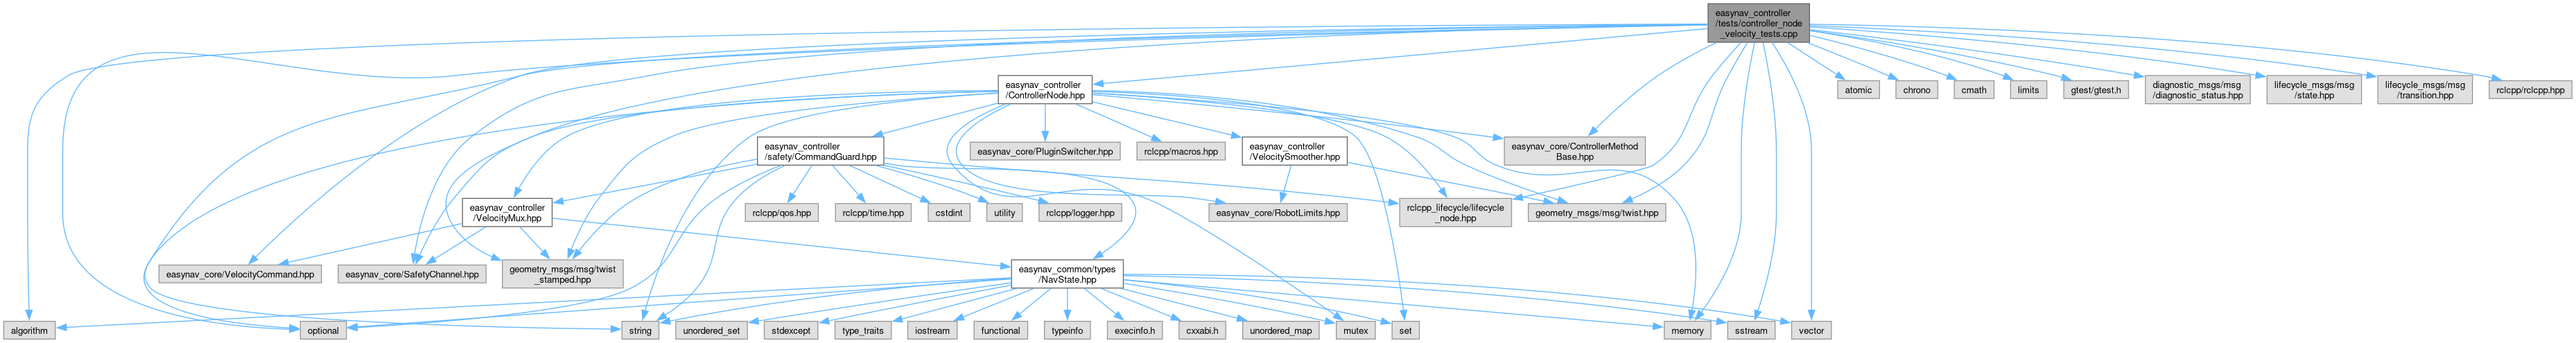
#include <algorithm>#include <atomic>#include <chrono>#include <cmath>#include <limits>#include <memory>#include <optional>#include <sstream>#include <string>#include <vector>#include "gtest/gtest.h"#include "diagnostic_msgs/msg/diagnostic_status.hpp"#include "geometry_msgs/msg/twist.hpp"#include "geometry_msgs/msg/twist_stamped.hpp"#include "lifecycle_msgs/msg/state.hpp"#include "lifecycle_msgs/msg/transition.hpp"#include "rclcpp/rclcpp.hpp"#include "rclcpp_lifecycle/lifecycle_node.hpp"#include "easynav_controller/ControllerNode.hpp"#include "easynav_core/ControllerMethodBase.hpp"#include "easynav_core/SafetyChannel.hpp"#include "easynav_core/VelocityCommand.hpp"
Include dependency graph for controller_node_velocity_tests.cpp:
Classes | |
| class | ControllerNodeSafetyChannelTest |
| class | ControllerNodeVelocityTest |
Functions | |
| TEST_F (ControllerNodeSafetyChannelTest, AProtectiveStopCommandsZeroAtOnceAndResumesFromZero) | |
| TEST_F (ControllerNodeSafetyChannelTest, AProtectiveStopIsPublishedEvenWithoutCommands) | |
| TEST_F (ControllerNodeSafetyChannelTest, ASpeedLimitAboveTheRobotLimitsChangesNothing) | |
| TEST_F (ControllerNodeSafetyChannelTest, ASpeedLimitAlsoCutsReversing) | |
| TEST_F (ControllerNodeSafetyChannelTest, ASpeedLimitCutsTheLimitsAndIsReachedBraking) | |
| TEST_F (ControllerNodeSafetyChannelTest, ASpeedLimitOfZeroHoldsTheRobot) | |
| TEST_F (ControllerNodeSafetyChannelTest, InhibitedMotionBrakesInARampAndResumes) | |
| TEST_F (ControllerNodeSafetyChannelTest, NewRobotLimitsKeepTheSpeedLimit) | |
| TEST_F (ControllerNodeSafetyChannelTest, NoSourceMovesTheRobotDuringAProtectiveStop) | |
| TEST_F (ControllerNodeSafetyChannelTest, ReconfiguringStartsWithoutTheSpeedLimit) | |
| TEST_F (ControllerNodeVelocityTest, AfterAnOverrideTheRampStartsFromIt) | |
| TEST_F (ControllerNodeVelocityTest, AtRestARestampedZeroIsNotRepublished) | |
| TEST_F (ControllerNodeVelocityTest, AtRestTheKeepaliveStillRepublishesTheRestampedZero) | |
| TEST_F (ControllerNodeVelocityTest, ControllerAskingToStopDeadIsBrakedWithinTheDecelerationLimit) | |
| TEST_F (ControllerNodeVelocityTest, ControllerPluginsQueryTheRobotLimitsFromTheNode) | |
| TEST_F (ControllerNodeVelocityTest, DeactivationBrakesInARampAndEndsWithAnExactZero) | |
| TEST_F (ControllerNodeVelocityTest, DeprecatedLimitsApplyWhenRobotLimitsAreNotConfigured) | |
| TEST_F (ControllerNodeVelocityTest, DeprecatedLimitsOutsideAControllerNode) | |
| TEST_F (ControllerNodeVelocityTest, DeprecatedLimitsSurviveReconfiguration) | |
| TEST_F (ControllerNodeVelocityTest, InvalidRobotLimitsFailToConfigure) | |
| TEST_F (ControllerNodeVelocityTest, KeepalivePublishesZeroAtRest) | |
| TEST_F (ControllerNodeVelocityTest, KeepaliveRepublishesTheHeldCommand) | |
| TEST_F (ControllerNodeVelocityTest, KeepsRampingWithoutNewCommandsAndThenStopsPublishing) | |
| TEST_F (ControllerNodeVelocityTest, KnowsWhichLimitsWereConfigured) | |
| TEST_F (ControllerNodeVelocityTest, NegativeOrNonFiniteTimeoutsFailToConfigure) | |
| TEST_F (ControllerNodeVelocityTest, NoDeprecatedLimitsMeansRobotLimits) | |
| TEST_F (ControllerNodeVelocityTest, NoNewCommandsBrakesToZeroAfterTheTimeoutAndResumes) | |
| TEST_F (ControllerNodeVelocityTest, NonFiniteCommandsAreNeverPublished) | |
| TEST_F (ControllerNodeVelocityTest, OverrideBypassesTheSmoother) | |
| TEST_F (ControllerNodeVelocityTest, PauseBrakesInARampAndResumeRampsUp) | |
| TEST_F (ControllerNodeVelocityTest, ProposalsArePrintedInTheNavStateDump) | |
| TEST_F (ControllerNodeVelocityTest, PublishesTheCommandRampingWithinTheLimits) | |
| TEST_F (ControllerNodeVelocityTest, ReceiverDetectsThatCommandsStopped) | |
| TEST_F (ControllerNodeVelocityTest, ReconfigurationStartsWithNoTimeoutState) | |
| TEST_F (ControllerNodeVelocityTest, ReconfigureRestoresTheConfiguredLimits) | |
| TEST_F (ControllerNodeVelocityTest, RobotLimitsTakePrecedenceOverDeprecatedOnes) | |
| TEST_F (ControllerNodeVelocityTest, SetRobotLimitsAppliesToTheSmoother) | |
| TEST_F (ControllerNodeVelocityTest, TakeoverIsPreferredAndSmoothedThenControlReturns) | |
| TEST_F (ControllerNodeVelocityTest, TakeoverWinsOverPauseAndOverrideOverEverything) | |
| TEST_F (ControllerNodeVelocityTest, TheDefaultTimeoutStopsAStaleCommand) | |
| TEST_F (ControllerNodeVelocityTest, TimeoutMustBeLongerThanTheControllerPeriod) | |
| TEST_F (ControllerNodeVelocityTest, VelocityQosKeepsOnlyTheLatestCommandAndOffersADeadline) | |
| TEST_F (ControllerNodeVelocityTest, ZeroVelocityLimitsAreValid) | |
Detailed Description
ControllerNode as the single exit of the velocity command: robot limits for the controller plugins, selection among sources (mux), smoothing, publication, and braking on deactivation.
Function Documentation
◆ TEST_F() [1/43]
| TEST_F | ( | ControllerNodeSafetyChannelTest | , |
| AProtectiveStopCommandsZeroAtOnceAndResumesFromZero | ) |
◆ TEST_F() [2/43]
| TEST_F | ( | ControllerNodeSafetyChannelTest | , |
| AProtectiveStopIsPublishedEvenWithoutCommands | ) |
◆ TEST_F() [3/43]
| TEST_F | ( | ControllerNodeSafetyChannelTest | , |
| ASpeedLimitAboveTheRobotLimitsChangesNothing | ) |
◆ TEST_F() [4/43]
| TEST_F | ( | ControllerNodeSafetyChannelTest | , |
| ASpeedLimitAlsoCutsReversing | ) |
◆ TEST_F() [5/43]
| TEST_F | ( | ControllerNodeSafetyChannelTest | , |
| ASpeedLimitCutsTheLimitsAndIsReachedBraking | ) |
◆ TEST_F() [6/43]
| TEST_F | ( | ControllerNodeSafetyChannelTest | , |
| ASpeedLimitOfZeroHoldsTheRobot | ) |
◆ TEST_F() [7/43]
| TEST_F | ( | ControllerNodeSafetyChannelTest | , |
| InhibitedMotionBrakesInARampAndResumes | ) |
◆ TEST_F() [8/43]
| TEST_F | ( | ControllerNodeSafetyChannelTest | , |
| NewRobotLimitsKeepTheSpeedLimit | ) |
◆ TEST_F() [9/43]
| TEST_F | ( | ControllerNodeSafetyChannelTest | , |
| NoSourceMovesTheRobotDuringAProtectiveStop | ) |
◆ TEST_F() [10/43]
| TEST_F | ( | ControllerNodeSafetyChannelTest | , |
| ReconfiguringStartsWithoutTheSpeedLimit | ) |
◆ TEST_F() [11/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| AfterAnOverrideTheRampStartsFromIt | ) |
◆ TEST_F() [12/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| AtRestARestampedZeroIsNotRepublished | ) |
◆ TEST_F() [13/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| AtRestTheKeepaliveStillRepublishesTheRestampedZero | ) |
◆ TEST_F() [14/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| ControllerAskingToStopDeadIsBrakedWithinTheDecelerationLimit | ) |
◆ TEST_F() [15/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| ControllerPluginsQueryTheRobotLimitsFromTheNode | ) |
◆ TEST_F() [16/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| DeactivationBrakesInARampAndEndsWithAnExactZero | ) |
◆ TEST_F() [17/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| DeprecatedLimitsApplyWhenRobotLimitsAreNotConfigured | ) |
◆ TEST_F() [18/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| DeprecatedLimitsOutsideAControllerNode | ) |
◆ TEST_F() [19/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| DeprecatedLimitsSurviveReconfiguration | ) |
◆ TEST_F() [20/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| InvalidRobotLimitsFailToConfigure | ) |
◆ TEST_F() [21/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| KeepalivePublishesZeroAtRest | ) |
◆ TEST_F() [22/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| KeepaliveRepublishesTheHeldCommand | ) |
◆ TEST_F() [23/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| KeepsRampingWithoutNewCommandsAndThenStopsPublishing | ) |
◆ TEST_F() [24/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| KnowsWhichLimitsWereConfigured | ) |
◆ TEST_F() [25/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| NegativeOrNonFiniteTimeoutsFailToConfigure | ) |
◆ TEST_F() [26/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| NoDeprecatedLimitsMeansRobotLimits | ) |
◆ TEST_F() [27/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| NoNewCommandsBrakesToZeroAfterTheTimeoutAndResumes | ) |
◆ TEST_F() [28/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| NonFiniteCommandsAreNeverPublished | ) |
◆ TEST_F() [29/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| OverrideBypassesTheSmoother | ) |
◆ TEST_F() [30/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| PauseBrakesInARampAndResumeRampsUp | ) |
◆ TEST_F() [31/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| ProposalsArePrintedInTheNavStateDump | ) |
◆ TEST_F() [32/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| PublishesTheCommandRampingWithinTheLimits | ) |
◆ TEST_F() [33/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| ReceiverDetectsThatCommandsStopped | ) |
◆ TEST_F() [34/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| ReconfigurationStartsWithNoTimeoutState | ) |
◆ TEST_F() [35/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| ReconfigureRestoresTheConfiguredLimits | ) |
◆ TEST_F() [36/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| RobotLimitsTakePrecedenceOverDeprecatedOnes | ) |
◆ TEST_F() [37/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| SetRobotLimitsAppliesToTheSmoother | ) |
◆ TEST_F() [38/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| TakeoverIsPreferredAndSmoothedThenControlReturns | ) |
◆ TEST_F() [39/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| TakeoverWinsOverPauseAndOverrideOverEverything | ) |
◆ TEST_F() [40/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| TheDefaultTimeoutStopsAStaleCommand | ) |
◆ TEST_F() [41/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| TimeoutMustBeLongerThanTheControllerPeriod | ) |
◆ TEST_F() [42/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| VelocityQosKeepsOnlyTheLatestCommandAndOffersADeadline | ) |
◆ TEST_F() [43/43]
| TEST_F | ( | ControllerNodeVelocityTest | , |
| ZeroVelocityLimitsAreValid | ) |
Generated by
 1.18.0