tests Directory Reference
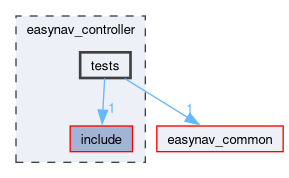
Directory dependency graph for tests:
Files | |
| command_guard_tests.cpp | |
| safety::CommandGuard around the VelocityMux: timeout, non-finite commands, new controller commands, keepalive, QoS and diagnostics. | |
| controller_node_tests.cpp | |
| controller_node_velocity_tests.cpp | |
| ControllerNode as the single exit of the velocity command: robot limits for the controller plugins, selection among sources (mux), smoothing, publication, and braking on deactivation. | |
| faulty_controller_tests.cpp | |
| How ControllerNode copes with a controller plugin that misbehaves (FaultyController). | |
| rt_allocation_tests.cpp | |
| The RT velocity path (proposals, mux, smoother) must not allocate memory once warm. | |
| velocity_mux_tests.cpp | |
| velocity_smoother_tests.cpp | |
Generated by
 1.18.0