How ControllerNode copes with a controller plugin that misbehaves (FaultyController). More...
#include <atomic>#include <chrono>#include <cmath>#include <memory>#include <optional>#include <string>#include <thread>#include <vector>#include "gtest/gtest.h"#include "diagnostic_msgs/msg/diagnostic_status.hpp"#include "geometry_msgs/msg/twist_stamped.hpp"#include "lifecycle_msgs/msg/state.hpp"#include "lifecycle_msgs/msg/transition.hpp"#include "rclcpp/rclcpp.hpp"#include "easynav_controller/ControllerNode.hpp"
Include dependency graph for faulty_controller_tests.cpp:
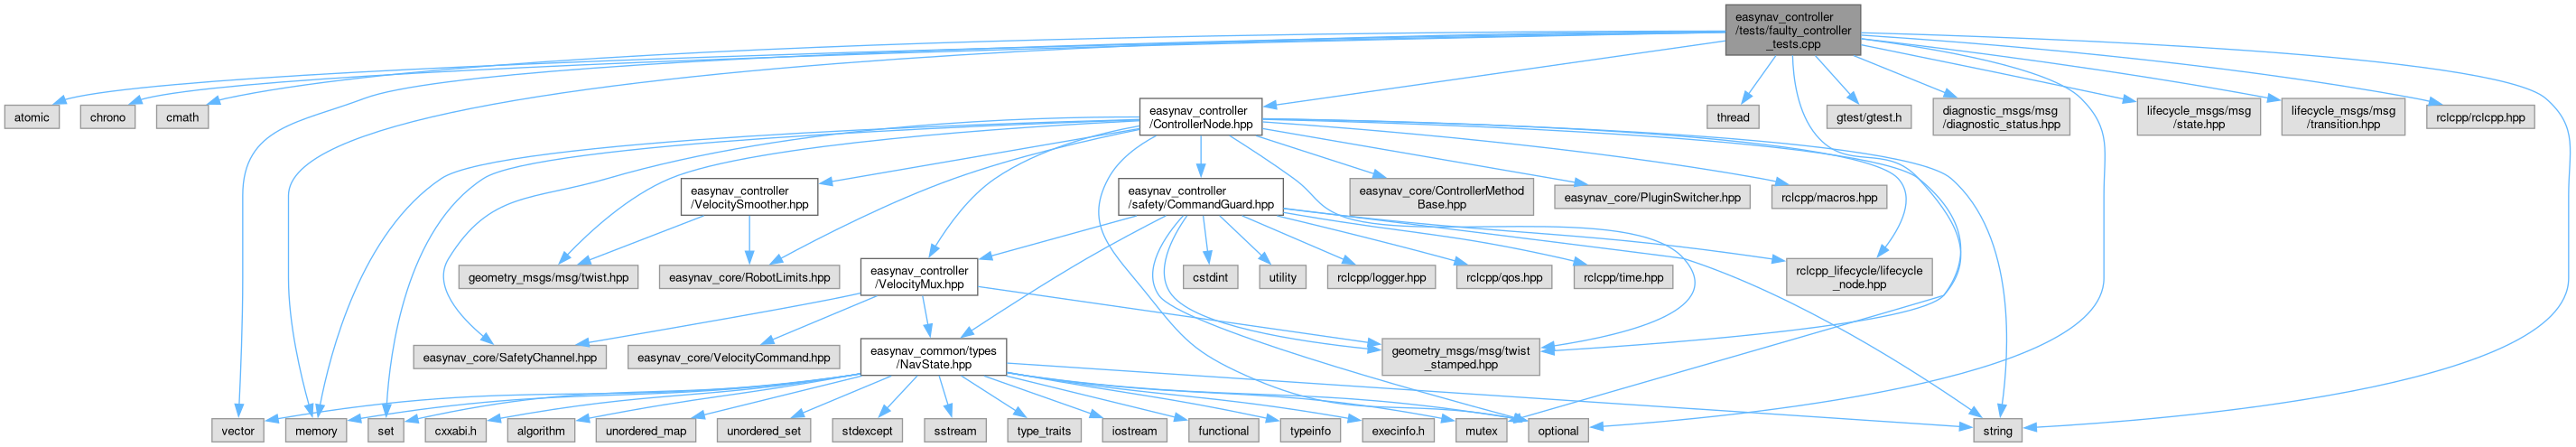
Classes | |
| class | FaultyControllerTest |
Functions | |
| TEST_F (FaultyControllerTest, ControllerThatFreezesIsStopped) | |
| TEST_F (FaultyControllerTest, ControllerThatStopsProposingIsStopped) | |
| TEST_F (FaultyControllerTest, ControllerThatThrowsIsStoppedAndEasyNavSurvives) | |
| TEST_F (FaultyControllerTest, FaultAfterLetsTheFirstUpdatesThrough) | |
| TEST_F (FaultyControllerTest, FreezingBeforeAnyCommandNeverMovesTheRobot) | |
| TEST_F (FaultyControllerTest, HangingControllerIsDetectedByTheReceiverDeadline) | |
| TEST_F (FaultyControllerTest, HugeCommandsAreClampedToTheRobotLimits) | |
| TEST_F (FaultyControllerTest, NaNCommandsAreNeverPublishedAndEndInAStop) | |
| TEST_F (FaultyControllerTest, NoFaultReachesTheCommandedVelocity) | |
| TEST_F (FaultyControllerTest, NominalAngularVelocityIsCommandedWithinTheLimits) | |
| TEST_F (FaultyControllerTest, ReconfiguringRestartsTheFaultCount) | |
| TEST_F (FaultyControllerTest, UnknownFaultFailsToConfigure) | |
Detailed Description
How ControllerNode copes with a controller plugin that misbehaves (FaultyController).
Function Documentation
◆ TEST_F() [1/12]
| TEST_F | ( | FaultyControllerTest | , |
| ControllerThatFreezesIsStopped | ) |
◆ TEST_F() [2/12]
| TEST_F | ( | FaultyControllerTest | , |
| ControllerThatStopsProposingIsStopped | ) |
◆ TEST_F() [3/12]
| TEST_F | ( | FaultyControllerTest | , |
| ControllerThatThrowsIsStoppedAndEasyNavSurvives | ) |
◆ TEST_F() [4/12]
| TEST_F | ( | FaultyControllerTest | , |
| FaultAfterLetsTheFirstUpdatesThrough | ) |
◆ TEST_F() [5/12]
| TEST_F | ( | FaultyControllerTest | , |
| FreezingBeforeAnyCommandNeverMovesTheRobot | ) |
◆ TEST_F() [6/12]
| TEST_F | ( | FaultyControllerTest | , |
| HangingControllerIsDetectedByTheReceiverDeadline | ) |
◆ TEST_F() [7/12]
| TEST_F | ( | FaultyControllerTest | , |
| HugeCommandsAreClampedToTheRobotLimits | ) |
◆ TEST_F() [8/12]
| TEST_F | ( | FaultyControllerTest | , |
| NaNCommandsAreNeverPublishedAndEndInAStop | ) |
◆ TEST_F() [9/12]
| TEST_F | ( | FaultyControllerTest | , |
| NoFaultReachesTheCommandedVelocity | ) |
◆ TEST_F() [10/12]
| TEST_F | ( | FaultyControllerTest | , |
| NominalAngularVelocityIsCommandedWithinTheLimits | ) |
◆ TEST_F() [11/12]
| TEST_F | ( | FaultyControllerTest | , |
| ReconfiguringRestartsTheFaultCount | ) |
◆ TEST_F() [12/12]
| TEST_F | ( | FaultyControllerTest | , |
| UnknownFaultFailsToConfigure | ) |
Generated by
 1.18.0