Occupancy.hpp File Reference
Probabilistic occupancy per NavCel: log-odds with clamping (as OctoMap), stored in an int16 layer in fixed point, and a three-state classification (as UFOMap). More...
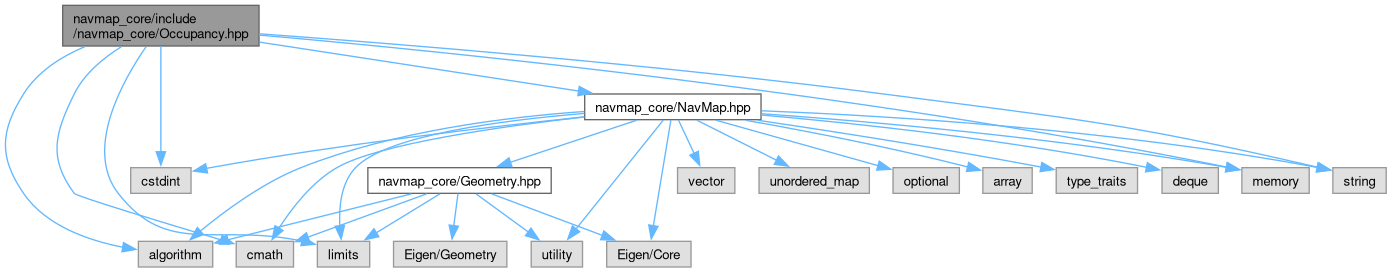
#include <algorithm>#include <cmath>#include <cstdint>#include <limits>#include <memory>#include <string>#include "navmap_core/NavMap.hpp"
Include dependency graph for Occupancy.hpp:
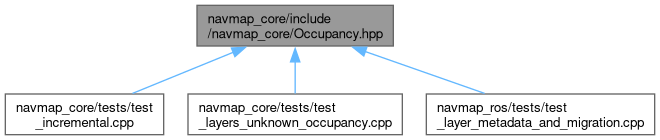
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Classes | |
| class | OccupancyLayer |
| Log-odds occupancy over an int16 layer of a NavMap. More... | |
| struct | OccupancyParams |
| Probabilities of the update rule and of the classification (OctoMap defaults). More... | |
Namespaces | |
| namespace | navmap |
Enumerations | |
| enum class | OccupancyState : uint8_t { UNKNOWN = 0 , FREE = 1 , OCCUPIED = 2 } |
| Three-state classification of a NavCel. More... | |
Detailed Description
Probabilistic occupancy per NavCel: log-odds with clamping (as OctoMap), stored in an int16 layer in fixed point, and a three-state classification (as UFOMap).
This is the update rule only. Which NavCels a measurement hits or traverses (the sensor model) is decided by the algorithm that uses it.
Generated by
 1.18.0