Classes |
Public Member Functions |
Public Attributes |
Static Public Attributes |
List of all members
NavMap Class Reference
#include <NavMap.hpp>
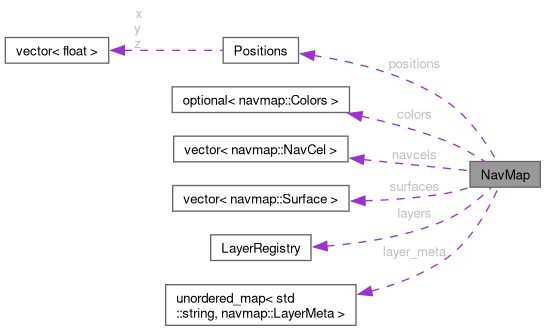
Collaboration diagram for NavMap:
Classes | |
| struct | LocateOpts |
| Options for the locate functions. More... | |
Public Member Functions | |
| template<typename T> | |
| std::shared_ptr< LayerView< T > > | add_layer (const std::string &name, const std::string &description, const std::string &unit, const std::string &src_layer) |
| Create (or get) a typed per-NavCel layer, initialized from another layer. | |
| template<typename T> | |
| std::shared_ptr< LayerView< T > > | add_layer (const std::string &name, const std::string &description={}, const std::string &unit={}, T default_value=T{}) |
| Create (or get) a typed per-NavCel layer with a default value. | |
| std::size_t | add_link (NavCelId from, NavCelId to, LinkType type=LinkType::GENERIC, float length=-1.0f, bool bidirectional=true) |
Add a link from from to to. | |
| NavCelId | add_navcel (uint32_t v0, uint32_t v1, uint32_t v2) |
| Append a triangle (NavCel) and return its id. | |
| void | add_navcel_to_surface (std::size_t surface_index, NavCelId cid) |
| Add an existing nav cell id to a surface. | |
| std::size_t | add_surface (const Surface &s) |
| Append an existing Surface (by value). | |
| std::size_t | add_surface (Surface &&s) |
| Add a Surface by move (avoids copy). | |
| uint32_t | add_vertex (const Eigen::Vector3f &p) |
| Append a vertex and return its index. | |
| void | build_adjacency () |
| Build topological adjacency between neighboring NavCels. | |
| void | clear_links () |
| bool | closest_navcel (const Eigen::Vector3f &p_world, size_t &surface_idx, NavCelId &cid, Eigen::Vector3f &closest_point, float &sqdist, int restrict_surface=-1) const |
| Find the closest triangle to a point. | |
| std::size_t | create_surface (std::string frame_id) |
| Create a new empty Surface and append it to the map. | |
| Surface | create_surface_obj (const std::string &frame_id) const |
| Create a standalone Surface object (not yet added to the map). | |
| std::vector< float > | distance_field (const std::vector< NavCelId > &seed_cells, bool from_boundary, float max_distance=std::numeric_limits< float >::infinity()) const |
| Distance (m, 3D) from each NavCel centroid to the nearest seed. | |
| std::uint64_t | geometry_id () const |
| Fingerprint of the geometry (vertex positions and triangles), 64-bit FNV-1a. | |
| std::optional< LayerMeta > | get_layer_meta (const std::string &name) const |
| Return metadata for a layer if present (implementation-defined). | |
| std::array< NavCelId, 3 > | get_neighbors (NavCelId cid) const |
Return the three neighbor NavCel ids of triangle cid. | |
| bool | has_layer (const std::string &name) const |
Check whether a layer named name exists. | |
| bool | has_same_geometry (const NavMap &other) const |
| Fast check for identical geometry (vertices and NavCel indices). | |
| bool | is_unknown (const std::string &name, NavCelId cid) const |
Whether layer name holds its unknown value at cid (false if it has none). | |
| template<typename T> | |
| void | layer_clear (const std::string &name, T value=T{}) |
| Reset all values in a layer to a given value. | |
| template<typename T> | |
| bool | layer_copy (const std::string &src, const std::string &dst) |
| Copy values from one layer into another. | |
| template<typename T> | |
| T | layer_get (const std::string &name, NavCelId cid, T def=T{}) const |
| Get a per-cell value as the requested type. | |
| template<typename T> | |
| void | layer_set (const std::string &name, NavCelId cid, T value) |
| Set a per-cell value (creates/retypes the layer if needed). | |
| std::size_t | layer_size (const std::string &name) const |
| Number of entries in a layer (should equal navcels.size()). | |
| std::string | layer_type_name (const std::string &name) const |
| Human-readable type name for a layer ("float", "double", "uint8", ...). | |
| const std::vector< SurfaceLink > & | links () const |
| const std::vector< std::uint32_t > & | links_from (NavCelId cid) const |
Indices of the links that can be taken from cid (both ends of bidirectional ones). | |
| std::vector< std::string > | list_layers () const |
| List all layer names currently stored. | |
| bool | locate_navcel (const Eigen::Vector3f &p_world, size_t &surface_idx, NavCelId &cid, Eigen::Vector3f &bary, Eigen::Vector3f *hit_pt) const |
| Locate the triangle under / near a world point (convenience). | |
| bool | locate_navcel (const Eigen::Vector3f &p_world, size_t &surface_idx, NavCelId &cid, Eigen::Vector3f &bary, Eigen::Vector3f *hit_pt, const LocateOpts &opts) const |
| Locate the triangle under / near a world point. | |
| bool | locate_navcel_core (const Eigen::Vector3f &p_world, std::size_t &surface_idx, NavCelId &cid, Eigen::Vector3f &bary, Eigen::Vector3f *hit_pt, const LocateOpts &opts) const |
| Forward to the existing low-level locator (implemented in .cpp). | |
| void | mark_vertex_updated (PointId) |
| Mark a vertex as updated (reserved for future cache invalidation). | |
| Eigen::Vector3f | navcel_centroid (NavCelId cid) const |
| Triangle centroid (computed on the fly). | |
| std::vector< NavCelId > | navcel_neighbors (NavCelId cid) const |
| Return up to 3 neighbor cell ids (skips invalid entries). | |
| template<typename T> | |
| T | navcel_value (NavCelId cid, const LayerView< T > &layer) const |
Read the value of a typed per-NavCel layer at triangle cid. | |
| NavMap () | |
| Copy constructor: deep copy of geometry, surfaces, layers and metadata. | |
| NavMap (const NavMap &other) | |
| Copy constructor: deep copy of geometry, surfaces, layers and metadata. | |
| std::size_t | nonmanifold_edges () const |
| Edges shared by more than two NavCels in the last adjacency build. | |
| NavMap & | operator= (const NavMap &other) |
| Copy assignment optimized to avoid geometry duplication. | |
| NavMap & | operator= (NavMap &&other) noexcept |
| Move assignment. | |
| bool | raycast (const Eigen::Vector3f &o, const Eigen::Vector3f &d, NavCelId &hit_cid, float &t, Eigen::Vector3f &hit_pt) const |
| Raycast against all surfaces to find the closest hit. | |
| void | raycast_many (const std::vector< Ray > &rays, std::vector< RayHit > &out, bool first_hit_only=true) const |
| Batched raycast. | |
| void | rebuild_geometry_accels () |
| Recompute derived geometry and acceleration structures. | |
| bool | remove_link (std::size_t index) |
Remove link index (the last link takes its index). False if out of range. | |
| bool | remove_surface (std::size_t surface_index) |
| Remove a Surface by index. | |
| double | sample_layer_at (const std::string &name, const Eigen::Vector3f &p_world, double def=std::numeric_limits< double >::quiet_NaN()) const |
| Sample a per-NavCel layer at a world position. | |
| template<typename T> | |
| bool | set_area (const Eigen::Vector3f &p_world, T value, const std::string &layer_name, AreaShape shape, float size) |
| Set a per-NavCel layer to a constant value over a 2D area. | |
| void | set_layer_unknown (const std::string &name, double value) |
Declare the value of layer name that means "not observed" (NaN allowed). | |
| std::size_t | surface_of (NavCelId cid) const |
Index of the surface owning cid, or kNoSurface. | |
Public Attributes | |
| std::optional< Colors > | colors |
| Optional per-vertex colors. | |
| std::unordered_map< std::string, LayerMeta > | layer_meta |
| Optional metadata per layer. | |
| LayerRegistry | layers |
| Per-NavCel layers (runtime registry). | |
| std::vector< NavCel > | navcels |
| All triangles (global indexing). | |
| Positions | positions |
| Vertex positions (SoA). | |
| std::vector< Surface > | surfaces |
| Surfaces (partitions of navcels). | |
Static Public Attributes | |
| static constexpr std::size_t | kInvalidLink = std::numeric_limits<std::size_t>::max() |
| Value returned by add_link() when a NavCel id is out of range. | |
| static constexpr std::size_t | kNoSurface = std::numeric_limits<std::size_t>::max() |
| Value returned by surface_of() for a NavCel in no surface. | |
Constructor & Destructor Documentation
◆ NavMap() [1/2]
| NavMap | ( | ) |
Copy constructor: deep copy of geometry, surfaces, layers and metadata.
◆ NavMap() [2/2]
Copy constructor: deep copy of geometry, surfaces, layers and metadata.
Member Function Documentation
◆ add_layer() [1/2]
template<typename T>
| std::shared_ptr< LayerView< T > > add_layer | ( | const std::string & | name, |
| const std::string & | description, | ||
| const std::string & | unit, | ||
| const std::string & | src_layer ) |
Create (or get) a typed per-NavCel layer, initialized from another layer.
If a layer with name exists, it is returned (size preserved). If the size differs from navcels.size(), it is resized. If the source layer src_layer exists, its values are copied into the destination using layer_copy(), performing type conversion if necessary. If the source layer does not exist, the destination is left with defaults.
- Template Parameters
-
T Storage type.
- Parameters
-
name Layer name. description Human-readable description (optional). unit Unit (e.g., "m", "deg", "%"), optional. src_layer Source layer name to initialize from.
- Returns
- Shared view of the created/updated layer.
◆ add_layer() [2/2]
template<typename T>
| std::shared_ptr< LayerView< T > > add_layer | ( | const std::string & | name, |
| const std::string & | description = {}, | ||
| const std::string & | unit = {}, | ||
| T | default_value = T{} ) |
Create (or get) a typed per-NavCel layer with a default value.
If a layer with name exists, it is returned (size preserved). If the size differs from navcels.size(), values are reinitialized to default_value.
- Template Parameters
-
T Storage type.
- Parameters
-
name Layer name. description Human-readable description (optional). unit Unit (e.g., "m", "deg", "%"), optional. default_value Initial value for all triangles.
- Returns
- Shared view of the created/updated layer.
◆ add_link()
| std::size_t add_link | ( | NavCelId | from, |
| NavCelId | to, | ||
| LinkType | type = LinkType::GENERIC, | ||
| float | length = -1.0f, | ||
| bool | bidirectional = true ) |
Add a link from from to to.
A negative length takes the distance between their centroids.
- Returns
- Index of the link, or kInvalidLink if an id is out of range or from == to.
◆ add_navcel()
| NavCelId add_navcel | ( | uint32_t | v0, |
| uint32_t | v1, | ||
| uint32_t | v2 ) |
Append a triangle (NavCel) and return its id.
- Parameters
-
v0 Index of vertex 0. v1 Index of vertex 1. v2 Index of vertex 2.
◆ add_navcel_to_surface()
| void add_navcel_to_surface | ( | std::size_t | surface_index, |
| NavCelId | cid ) |
Add an existing nav cell id to a surface.
◆ add_surface() [1/2]
| std::size_t add_surface | ( | const Surface & | s | ) |
◆ add_surface() [2/2]
| std::size_t add_surface | ( | Surface && | s | ) |
◆ add_vertex()
| uint32_t add_vertex | ( | const Eigen::Vector3f & | p | ) |
Append a vertex and return its index.
◆ build_adjacency()
| void build_adjacency | ( | ) |
Build topological adjacency between neighboring NavCels.
Two triangles are neighbors if they share an undirected edge and no other triangle uses it; edges shared by more than two (non-manifold) stay open. Called by rebuild_geometry_accels().
◆ clear_links()
| void clear_links | ( | ) |
◆ closest_navcel()
| bool closest_navcel | ( | const Eigen::Vector3f & | p_world, |
| size_t & | surface_idx, | ||
| NavCelId & | cid, | ||
| Eigen::Vector3f & | closest_point, | ||
| float & | sqdist, | ||
| int | restrict_surface = -1 ) const |
Find the closest triangle to a point.
Traverses per-surface BVHs with distance lower-bounds; returns the closest triangle, the closest point on it, and the squared distance.
- Parameters
-
p_world Query point in world coordinates. [out] surface_idx Surface index of the closest triangle. [out] cid NavCel id of the closest triangle. [out] closest_point Closest point on that triangle. [out] sqdist Squared distance to p_world.restrict_surface If >= 0, restrict search to this surface.
- Returns
- true if any triangle was considered.
◆ create_surface()
| std::size_t create_surface | ( | std::string | frame_id | ) |
◆ create_surface_obj()
| Surface create_surface_obj | ( | const std::string & | frame_id | ) | const |
◆ distance_field()
| std::vector< float > distance_field | ( | const std::vector< NavCelId > & | seed_cells, |
| bool | from_boundary, | ||
| float | max_distance = std::numeric_limits<float>::infinity() ) const |
Distance (m, 3D) from each NavCel centroid to the nearest seed.
Seeds are the centroids of seed_cells and, if from_boundary, the open edges of the mesh (edges without a neighbor: walls, drops, unmapped space). The nearest seed is propagated over adjacency and the distance is measured straight to it, so it never jumps between disconnected surfaces (e.g. stacked floors).
- Parameters
-
seed_cells Seed NavCels (out-of-range ids are ignored). from_boundary Also seed the open edges. max_distance Stop beyond this distance; farther or unreachable cells get +inf.
- Returns
- One distance per NavCel.
◆ geometry_id()
| std::uint64_t geometry_id | ( | ) | const |
Fingerprint of the geometry (vertex positions and triangles), 64-bit FNV-1a.
Equal maps have equal ids, so a layer update can name the geometry it belongs to. Recomputed lazily after add_vertex(), add_navcel() or rebuild_geometry_accels(); call the latter after editing positions or navcels directly.
◆ get_layer_meta()
| std::optional< LayerMeta > get_layer_meta | ( | const std::string & | name | ) | const |
Return metadata for a layer if present (implementation-defined).
- Parameters
-
name Layer name.
- Returns
- Optional metadata if available.
◆ get_neighbors()
◆ has_layer()
| bool has_layer | ( | const std::string & | name | ) | const |
Check whether a layer named name exists.
◆ has_same_geometry()
| bool has_same_geometry | ( | const NavMap & | other | ) | const |
Fast check for identical geometry (vertices and NavCel indices).
◆ is_unknown()
| bool is_unknown | ( | const std::string & | name, |
| NavCelId | cid ) const |
Whether layer name holds its unknown value at cid (false if it has none).
◆ layer_clear()
template<typename T>
| void layer_clear | ( | const std::string & | name, |
| T | value = T{} ) |
Reset all values in a layer to a given value.
- Parameters
-
T Expected storage type of the layer. name Layer name. value Value to assign to all entries.
◆ layer_copy()
template<typename T>
| bool layer_copy | ( | const std::string & | src, |
| const std::string & | dst ) |
Copy values from one layer into another.
Both layers must have the same type and size.
- Parameters
-
T Storage type (e.g. float, uint8_t). src Name of source layer. dst Name of destination layer.
- Returns
- true if copy succeeded, false if type/size mismatch.
◆ layer_get()
template<typename T>
| T layer_get | ( | const std::string & | name, |
| NavCelId | cid, | ||
| T | def = T{} ) const |
Get a per-cell value as the requested type.
If the stored type matches T, returns directly. Otherwise falls back to conversion vía double: floating → static_cast<T>, integral → clamp [0,max(T)] y redondeo (llround).
Si la capa no existe o cid está fuera de rango, devuelve def.
- Template Parameters
-
T uint8_t, int16_t, float, or double
- Parameters
-
name Layer name cid Triangle id def Default value on failure
- Returns
- Value converted to T, or
def
◆ layer_set()
template<typename T>
| void layer_set | ( | const std::string & | name, |
| NavCelId | cid, | ||
| T | value ) |
Set a per-cell value (creates/retypes the layer if needed).
- Template Parameters
-
T Storage type.
- Parameters
-
name Layer name. cid Triangle id. value Value to write.
◆ layer_size()
| std::size_t layer_size | ( | const std::string & | name | ) | const |
Number of entries in a layer (should equal navcels.size()).
◆ layer_type_name()
| std::string layer_type_name | ( | const std::string & | name | ) | const |
Human-readable type name for a layer ("float", "double", "uint8", ...).
◆ links()
| const std::vector< SurfaceLink > & links | ( | ) | const |
◆ links_from()
| const std::vector< std::uint32_t > & links_from | ( | NavCelId | cid | ) | const |
Indices of the links that can be taken from cid (both ends of bidirectional ones).
◆ list_layers()
| std::vector< std::string > list_layers | ( | ) | const |
List all layer names currently stored.
- Returns
- Vector of layer names.
◆ locate_navcel() [1/2]
| bool locate_navcel | ( | const Eigen::Vector3f & | p_world, |
| size_t & | surface_idx, | ||
| NavCelId & | cid, | ||
| Eigen::Vector3f & | bary, | ||
| Eigen::Vector3f * | hit_pt ) const |
Locate the triangle under / near a world point (convenience).
Uses default LocateOpts. See the full overload for details.
- Parameters
-
p_world Query point in world coordinates. [out] surface_idx Surface index owning the located triangle. [out] cid Located NavCel id. [out] bary Barycentric coordinates of the hit. [out] hit_pt Optional: projected point on the surface.
- Returns
- true if a triangle has been located.
◆ locate_navcel() [2/2]
| bool locate_navcel | ( | const Eigen::Vector3f & | p_world, |
| size_t & | surface_idx, | ||
| NavCelId & | cid, | ||
| Eigen::Vector3f & | bary, | ||
| Eigen::Vector3f * | hit_pt, | ||
| const LocateOpts & | opts ) const |
Locate the triangle under / near a world point.
Strategy: 1) If hint_cid is provided, try walking neighbors. 2) Else, try a per-surface 2D seed grid near (x,y) with planar test. 3) If still not found, vertical raycast (downward or upward).
- Parameters
-
p_world Query point in world coordinates. [out] surface_idx Surface index owning the located triangle. [out] cid Located NavCel id. [out] bary Barycentric coordinates of the hit. [out] hit_pt Optional: projected point on the surface. opts Tuning options (see LocateOpts).
- Returns
- true if a triangle has been located.
◆ locate_navcel_core()
| bool locate_navcel_core | ( | const Eigen::Vector3f & | p_world, |
| std::size_t & | surface_idx, | ||
| NavCelId & | cid, | ||
| Eigen::Vector3f & | bary, | ||
| Eigen::Vector3f * | hit_pt, | ||
| const LocateOpts & | opts ) const |
Forward to the existing low-level locator (implemented in .cpp).
This hook should call your original, detailed locator implementation. The robust overload above will fall back to vertical rays if needed.
◆ mark_vertex_updated()
| void mark_vertex_updated | ( | PointId | ) |
Mark a vertex as updated (reserved for future cache invalidation).
- Parameters
-
pid Vertex id (unused for now).
◆ navcel_centroid()
| Eigen::Vector3f navcel_centroid | ( | NavCelId | cid | ) | const |
Triangle centroid (computed on the fly).
◆ navcel_neighbors()
Return up to 3 neighbor cell ids (skips invalid entries).
◆ navcel_value()
Read the value of a typed per-NavCel layer at triangle cid.
- Template Parameters
-
T Layer storage type (must match the layer).
- Parameters
-
cid NavCel id. layer Typed layer view.
- Returns
- The value for triangle
cid.
◆ nonmanifold_edges()
| std::size_t nonmanifold_edges | ( | ) | const |
Edges shared by more than two NavCels in the last adjacency build.
◆ operator=() [1/2]
Copy assignment optimized to avoid geometry duplication.
If both maps share identical geometry (same vertex arrays and NavCel indices), layers are synchronized by name/type (copy-on-difference) and destination-only layers are removed. Otherwise, a full deep copy is performed.
◆ operator=() [2/2]
Move assignment.
Transfers ownership of geometry, surfaces, layers and metadata.
◆ raycast()
| bool raycast | ( | const Eigen::Vector3f & | o, |
| const Eigen::Vector3f & | d, | ||
| NavCelId & | hit_cid, | ||
| float & | t, | ||
| Eigen::Vector3f & | hit_pt ) const |
◆ raycast_many()
| void raycast_many | ( | const std::vector< Ray > & | rays, |
| std::vector< RayHit > & | out, | ||
| bool | first_hit_only = true ) const |
Batched raycast.
- Parameters
-
rays Input rays. [out] out Output hits (parallel to rays).first_hit_only If true, stop at the first surface that hits.
◆ rebuild_geometry_accels()
| void rebuild_geometry_accels | ( | ) |
Recompute derived geometry and acceleration structures.
Computes triangle normals and areas, builds adjacency between neighbors, and builds per-surface BVHs. Layer sizes are not changed automatically; call resize_all() if you modified navcels.
◆ remove_link()
| bool remove_link | ( | std::size_t | index | ) |
Remove link index (the last link takes its index). False if out of range.
◆ remove_surface()
| bool remove_surface | ( | std::size_t | surface_index | ) |
◆ sample_layer_at()
| double sample_layer_at | ( | const std::string & | name, |
| const Eigen::Vector3f & | p_world, | ||
| double | def = std::numeric_limits<double>::quiet_NaN() ) const |
Sample a per-NavCel layer at a world position.
Locates the containing triangle and returns its layer value.
- Parameters
-
name Layer name. p_world World-space query. def Default value if not found.
- Returns
- Value or
defif missing.
◆ set_area()
template<typename T>
| bool set_area | ( | const Eigen::Vector3f & | p_world, |
| T | value, | ||
| const std::string & | layer_name, | ||
| AreaShape | shape, | ||
| float | size ) |
Set a per-NavCel layer to a constant value over a 2D area.
The center is the ground projection of p_world. If the projected NavCel cannot be determined, returns false. Supports U8/F32/F64 layers.
Efficiency: BFS from the seed NavCel with XY AABB pruning against the circumscribed square of the area. Inclusion test by triangle centroid.
- Template Parameters
-
T uint8_t, int16_t, float, or double
- Parameters
-
p_world 3D point in world coordinates (projected to ground) value Value to set in the layer layer_name Target layer name shape CIRCULAR or RECTANGULAR size Radius (CIRCULAR) or side length (RECTANGULAR)
- Returns
- true if the seed NavCel was located and the layer updated
◆ set_layer_unknown()
| void set_layer_unknown | ( | const std::string & | name, |
| double | value ) |
Declare the value of layer name that means "not observed" (NaN allowed).
Travels with the map (message and file) and is kept by add_layer().
◆ surface_of()
| std::size_t surface_of | ( | NavCelId | cid | ) | const |
Index of the surface owning cid, or kNoSurface.
- Note
- O(1) after rebuild_geometry_accels().
Member Data Documentation
◆ colors
| std::optional<Colors> colors |
Optional per-vertex colors.
◆ kInvalidLink
|
staticconstexpr |
Value returned by add_link() when a NavCel id is out of range.
◆ kNoSurface
|
staticconstexpr |
Value returned by surface_of() for a NavCel in no surface.
◆ layer_meta
| std::unordered_map<std::string, LayerMeta> layer_meta |
Optional metadata per layer.
◆ layers
| LayerRegistry layers |
Per-NavCel layers (runtime registry).
◆ navcels
| std::vector<NavCel> navcels |
All triangles (global indexing).
◆ positions
| Positions positions |
Vertex positions (SoA).
◆ surfaces
The documentation for this class was generated from the following files:
- navmap_core/include/navmap_core/NavMap.hpp
- navmap_core/src/navmap_core/NavMap.cpp
Generated by
 1.18.0