Combine.hpp File Reference
Combining one layer into another with explicit operators, unknown-aware, with provenance. More...
#include <cstddef>#include <cstdint>#include <limits>#include <string>#include <vector>#include "navmap_core/NavMap.hpp"
Include dependency graph for Combine.hpp:
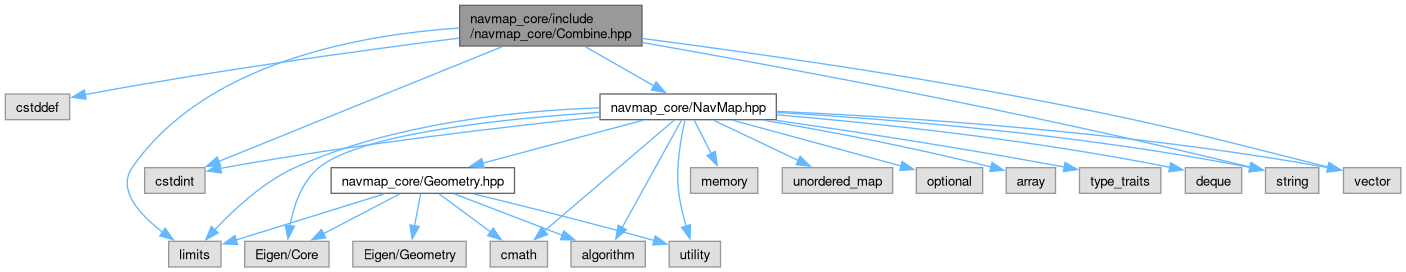
This graph shows which files directly or indirectly include this file:
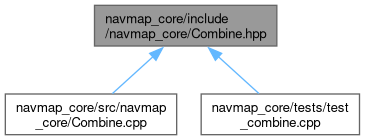
Go to the source code of this file.
Classes | |
| struct | CombineOptions |
| Options of combine_layer(). More... | |
Namespaces | |
| namespace | navmap |
Enumerations | |
| enum class | CombineOp : uint8_t { OVERWRITE , TRUE_OVERWRITE , MAX , MAX_KEEP_UNKNOWN , MIN , ADD } |
| How a source value s is combined into the destination value d (as costmap_2d's update modes). More... | |
Functions | |
| std::ptrdiff_t | combine_layer (NavMap &nm, const std::string &dst, const std::string &src, CombineOp op, const CombineOptions &options={}) |
Combine layer src into layer dst cell by cell with op. | |
Detailed Description
Combining one layer into another with explicit operators, unknown-aware, with provenance.
Each source (a static prior, obstacles from a sensor, a keep-out zone) keeps its own layer, and a master layer is composed from them. Clearing a source layer then never erases another source: a prior survives sensor clearing because it is never written by the sensor.
The cost convention (Costs.hpp) is that of costmap_2d / Nav2.
Generated by
 1.18.0