Descriptors.hpp File Reference
Geometric descriptors per NavCel (slope, roughness, step, clearance), as layers. More...
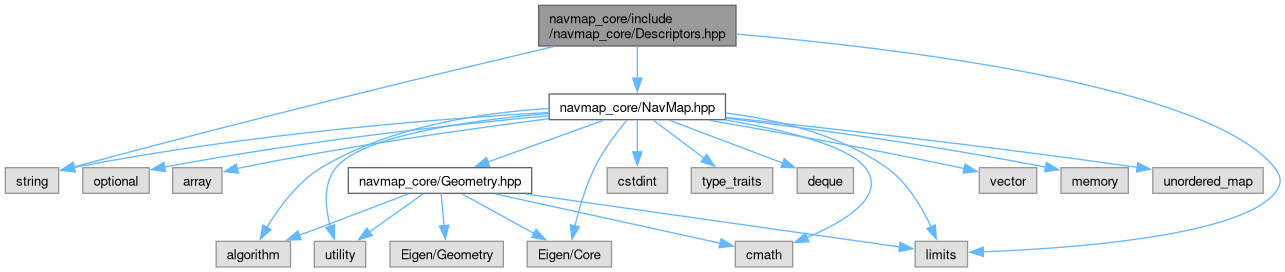
Include dependency graph for Descriptors.hpp:
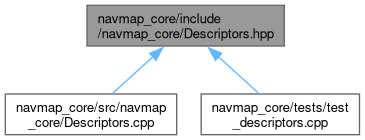
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Classes | |
| struct | DescriptorParams |
| Which descriptors to compute, and over which neighbourhoods. More... | |
Namespaces | |
| namespace | navmap |
Functions | |
| void | compute_descriptors (NavMap &nm, const DescriptorParams ¶ms={}) |
Compute the selected descriptors as F32 layers of nm (created or overwritten). | |
Detailed Description
Geometric descriptors per NavCel (slope, roughness, step, clearance), as layers.
They describe the surface only. Turning them into traversability or cost is a decision of the algorithm that uses them (a planner), not of the map.
Generated by
 1.18.0