navmap_io.hpp File Reference
Save/Load utilities for NavMap to/from disk using ROS 2 CDR serialization. More...
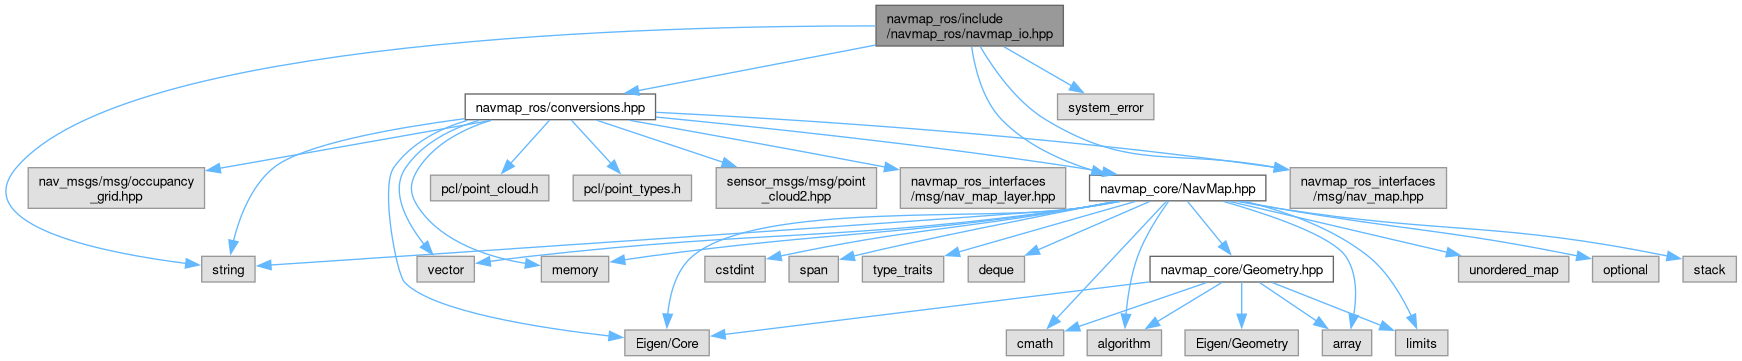
#include <string>#include <system_error>#include "navmap_core/NavMap.hpp"#include "navmap_ros_interfaces/msg/nav_map.hpp"
Include dependency graph for navmap_io.hpp:
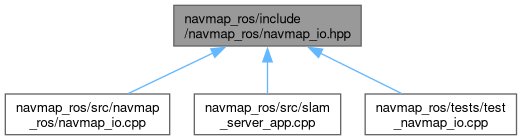
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Classes | |
| struct | SaveOptions |
| Save options. More... | |
Namespaces | |
| namespace | navmap_ros |
| Conversions between core NavMap and ROS-level structures. | |
| namespace | navmap_ros::io |
| IO helpers to persist NavMap objects to/from disk. | |
Enumerations | |
| enum class | Compression { NONE , ZLIB } |
| Payload compression. zlib is available on every ROS distro and platform, and in Python. More... | |
Functions | |
| bool | load_from_file (const std::string &path, navmap::NavMap &out_map, std::error_code *ec=nullptr) |
| Load a navmap::NavMap by deserializing a message and converting to core. | |
| bool | load_msg_from_file (const std::string &path, navmap_ros_interfaces::msg::NavMap &out_msg, std::error_code *ec=nullptr) |
| Load a NavMap message from a file created by this saver. | |
| bool | save_msg_to_file (const navmap_ros_interfaces::msg::NavMap &msg, const std::string &path, const SaveOptions &options={}, std::error_code *ec=nullptr) |
| Save a NavMap message to disk using ROS 2 CDR serialization. | |
| bool | save_to_file (const navmap::NavMap &map, const std::string &path, const SaveOptions &options={}, std::error_code *ec=nullptr) |
| Save a navmap::NavMap by converting it to a message and serializing to disk. | |
Detailed Description
Save/Load utilities for NavMap to/from disk using ROS 2 CDR serialization.
Two API layers: 1) Message-level: save/load navmap_ros_interfaces::msg::NavMap directly. 2) Core-level (optional): save/load navmap::NavMap if the core headers are available, using navmap_ros::to_msg / navmap_ros::from_msg.
- File format (version 2)
- A small binary envelope followed by the ROS 2-serialized payload (little endian):
- Magic "NAVMAP\0\0"
- Version (uint32), codec (uint32: 0 none, 1 zlib)
- Raw (CDR) size and stored size (uint64 each)
- Payload: the CDR message, compressed by the codec
Version 1 files (magic, version, size, CDR; or a bare CDR payload) are migrated on load, with a deprecation warning, and rewritten in the current format.
Generated by
 1.18.0