navmap_io.cpp File Reference
#include <unistd.h>#include <algorithm>#include <cstdio>#include <fstream>#include <vector>#include <cstring>#include <cerrno>#include "navmap_ros/navmap_io.hpp"#include "navmap_core/NavMap.hpp"#include "navmap_ros/conversions.hpp"#include "rclcpp/serialized_message.hpp"#include "rclcpp/serialization.hpp"#include "rclcpp/logging.hpp"#include "navmap_ros_interfaces/msg/nav_map_v1.hpp"#include "zlib.h"
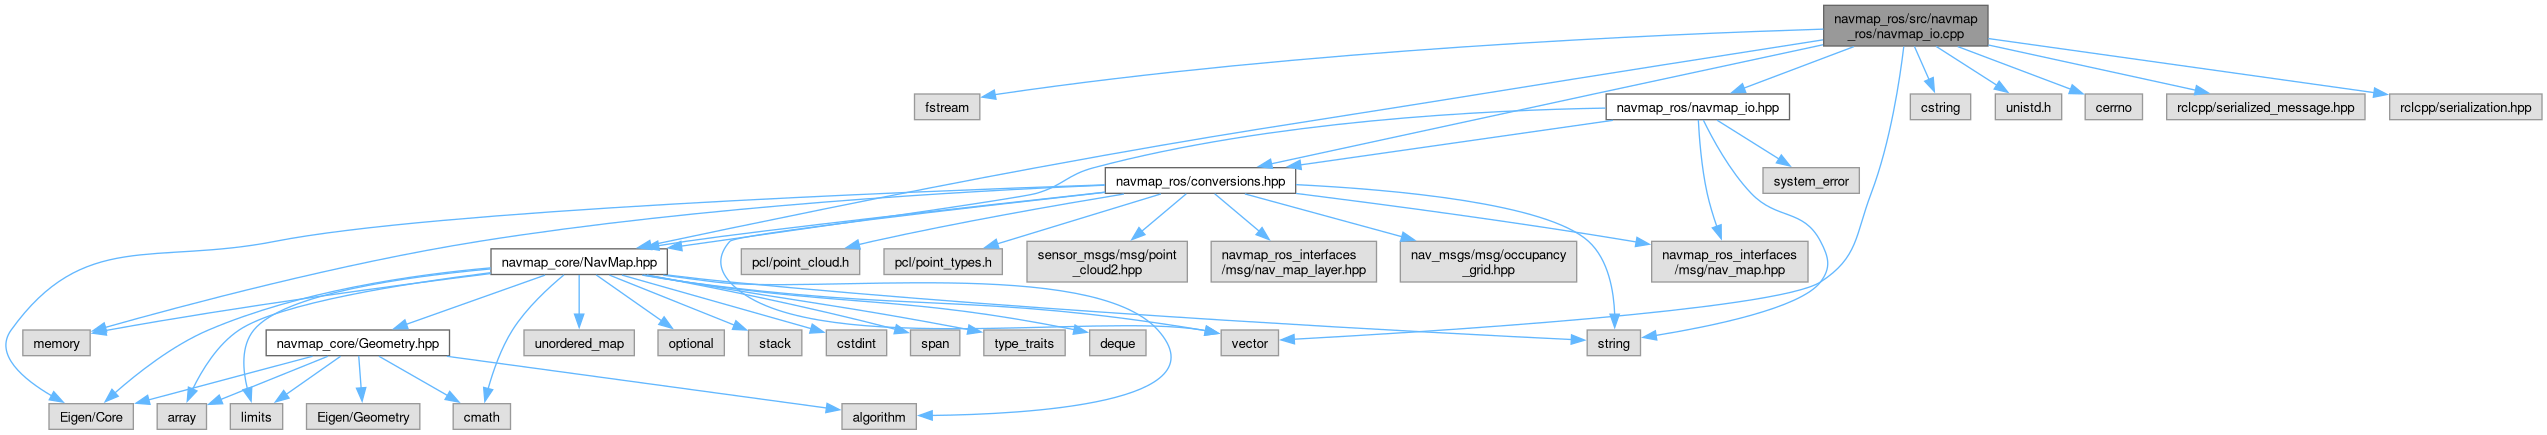
Include dependency graph for navmap_io.cpp:
Namespaces | |
| namespace | navmap_ros |
| Conversions between core NavMap and ROS-level structures. | |
| namespace | navmap_ros::io |
| IO helpers to persist NavMap objects to/from disk. | |
Functions | |
| bool | load_from_file (const std::string &path, navmap::NavMap &out_map, std::error_code *ec=nullptr) |
| Load a navmap::NavMap by deserializing a message and converting to core. | |
| bool | load_msg_from_file (const std::string &path, navmap_ros_interfaces::msg::NavMap &out_msg, std::error_code *ec=nullptr) |
| Load a NavMap message from a file created by this saver. | |
| bool | save_msg_to_file (const navmap_ros_interfaces::msg::NavMap &msg, const std::string &path, const SaveOptions &options={}, std::error_code *ec=nullptr) |
| Save a NavMap message to disk using ROS 2 CDR serialization. | |
| bool | save_to_file (const navmap::NavMap &map, const std::string &path, const SaveOptions &options={}, std::error_code *ec=nullptr) |
| Save a navmap::NavMap by converting it to a message and serializing to disk. | |
Generated by
 1.18.0