tests Directory Reference
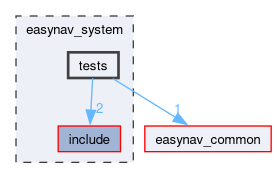
Directory dependency graph for tests:
Files | |
| goalmanager_tests.cpp | |
| real_time_tests.cpp | |
| Real-time setup of the EasyNav process. | |
| rt_monitor_tests.cpp | |
| safety::RtMonitor, with simulated cycle start times. | |
| safety_channel_monitor_tests.cpp | |
| SafetyChannelMonitor, with simulated times. | |
| safety_module_tests.cpp | |
| The safety module of easynav_system, on its own: configuration fingerprint, parameter freezer and safety supervisor. | |
| system_actions_tests.cpp | |
| SystemNode as SystemActions (what a recovery system can ask of EasyNav), and recovery_node as one more EasyNav node. | |
| system_clock_watchdog_tests.cpp | |
| SystemNode tells which EasyNav nodes have use_sim_time and no /clock (their components never run), and warns about them while Active. | |
| system_component_faults_tests.cpp | |
| SystemNode with a localizer, planner or maps manager that misbehaves (FaultyLocalizer, FaultyPlanner, FaultyMapsManager). | |
| system_fault_injection_tests.cpp | |
| The whole RT cycle of SystemNode with a controller that misbehaves (FaultyController). | |
| system_lifecycle_cycle_tests.cpp | |
| Exercises SystemNode's own lifecycle state machine through repeated full cycles, including active -> inactive -> unconfigured -> inactive -> active. | |
| system_lifecycle_mission_tests.cpp | |
| A mission survives reconfiguring EasyNav (active -> inactive -> unconfigured -> inactive -> active, as when switching plugins at runtime) in the middle of it. | |
| system_pause_tests.cpp | |
| system_robot_geometry_tests.cpp | |
| SystemNode shares "robot_geometry.*" with every component before they configure. | |
| system_safety_mode_tests.cpp | |
| Configuration validation, safety mode, frozen configuration and configuration hash. | |
| system_shutdown_request_tests.cpp | |
| A shutdown requested by a recovery mitigation takes SystemNode (and every EasyNav node) out of Active through the lifecycle's error path, ending in Finalized. | |
| system_tfinfo_tests.cpp | |
| system_velocity_smoothing_tests.cpp | |
| End to end through SystemNode: with very low accelerations, the published commands are smoothed, never a jump to the controller's command. | |
Generated by
 1.18.0